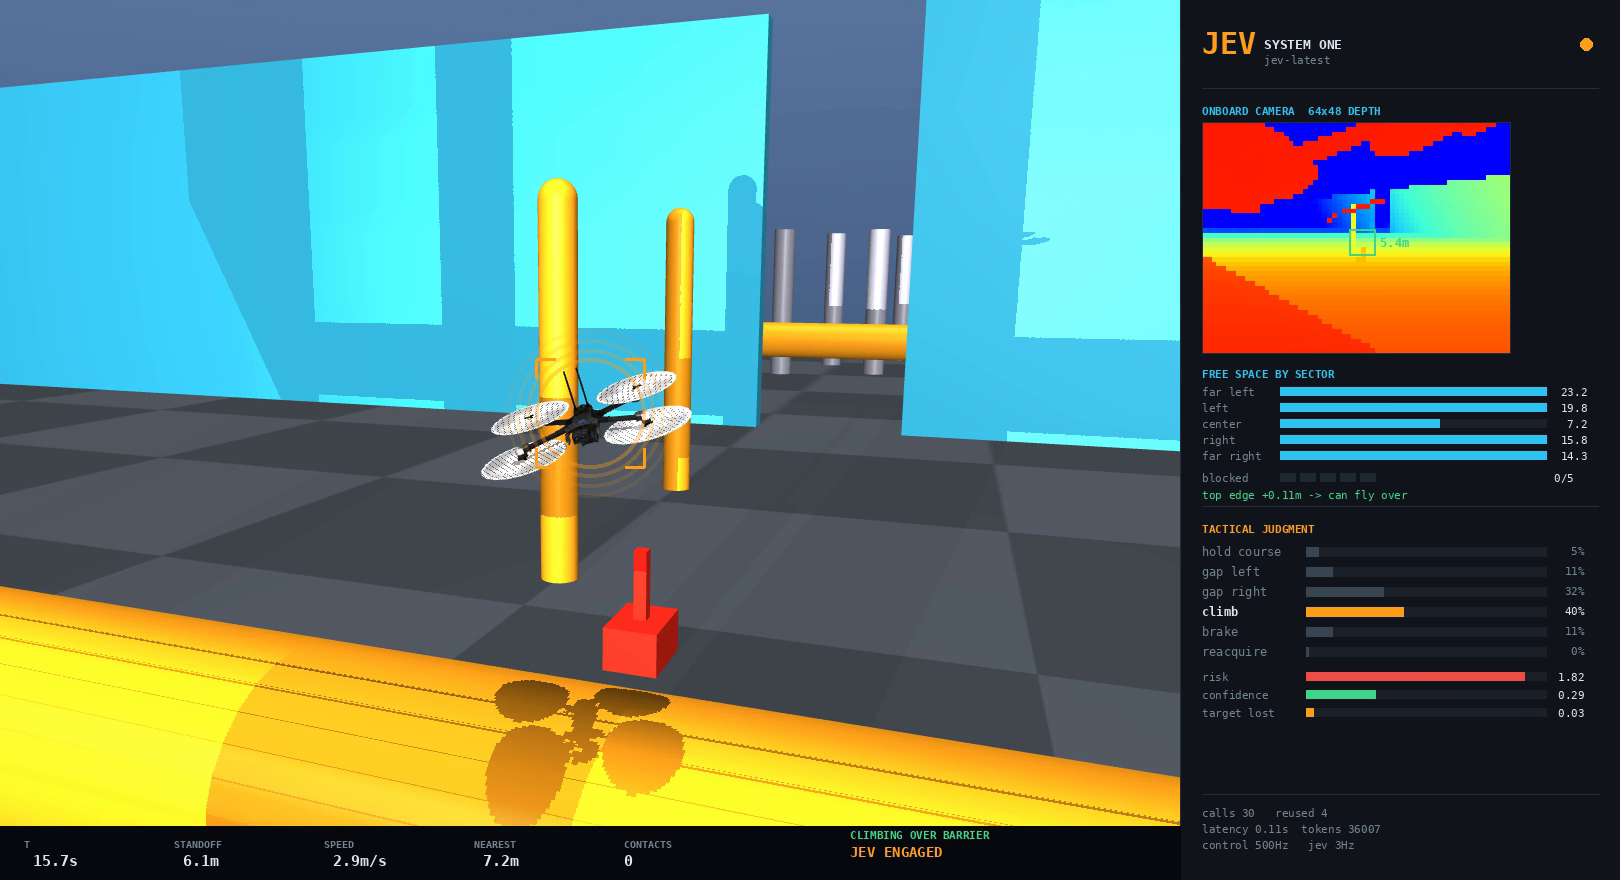
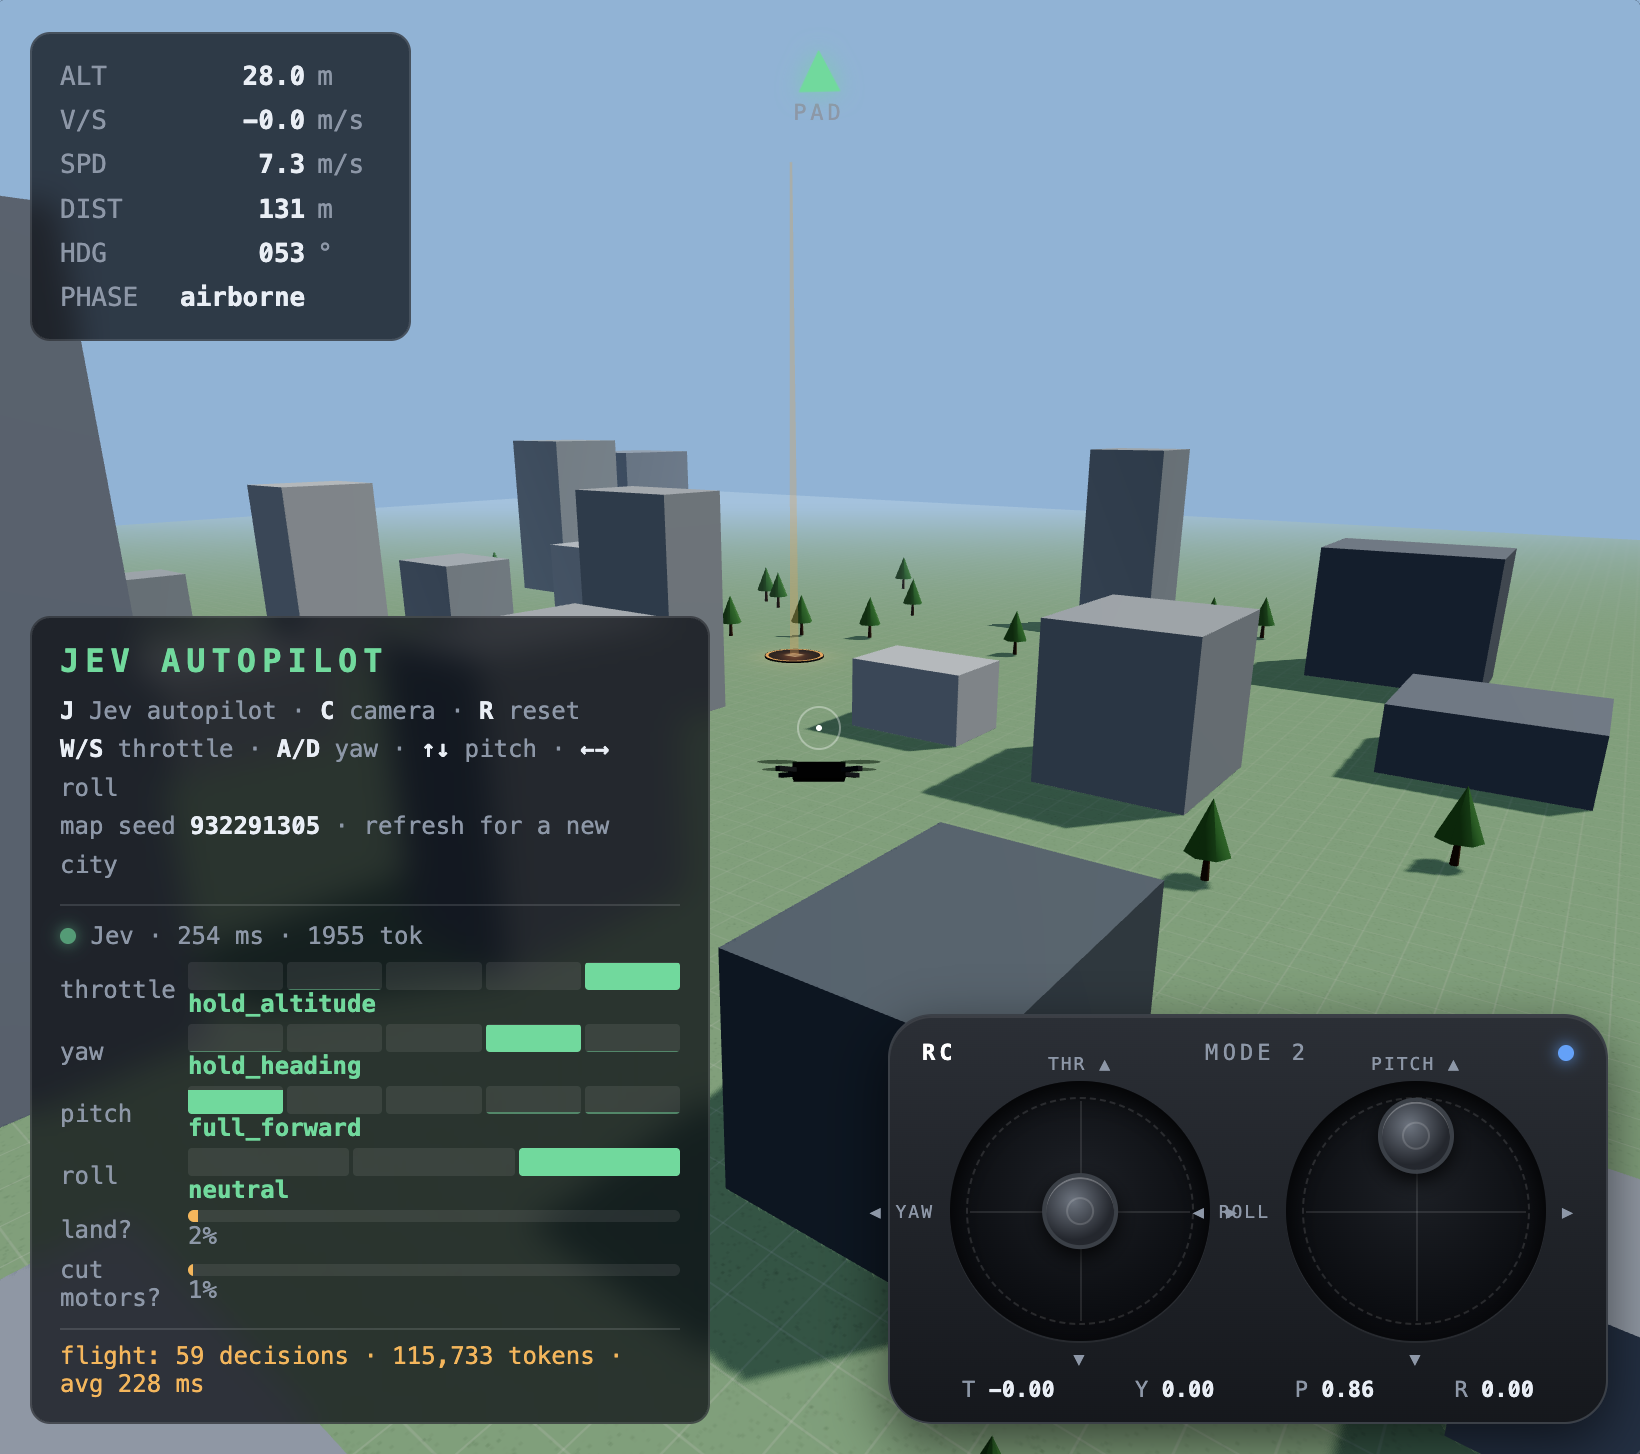
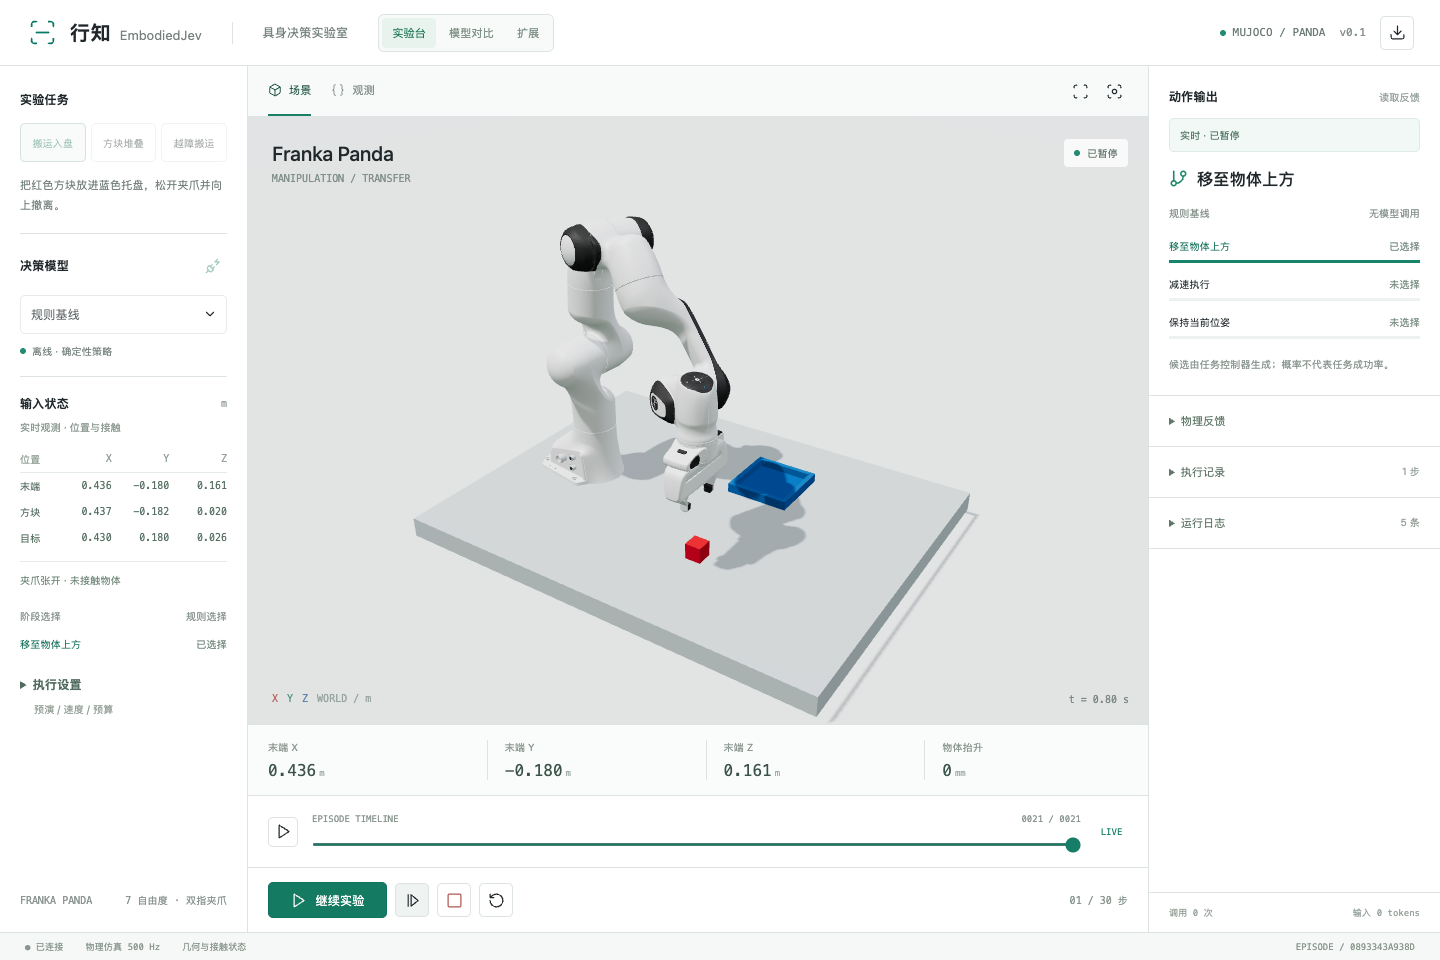
Jev vs LLM robot arm
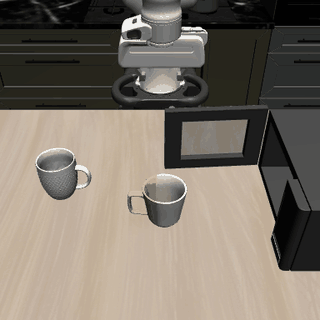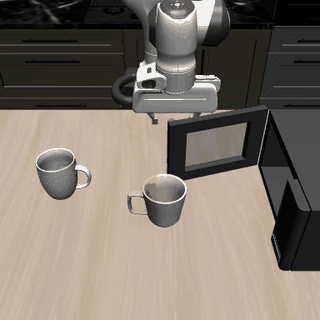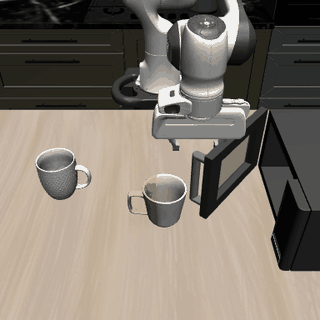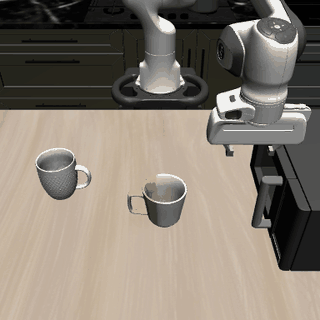
A simulated Franka arm stacks cubes in MuJoCo. Code previews candidate moves in physics; Jev chooses a move and judges grasp, release, and completion. The README reports one recorded run for each controller.
Jev (TypeSafe System One) vs Claude Opus 5 driving a simulated robot arm in MuJoCo
How it uses Jev
- agent.py : an LLM (Claude Opus 5 by default) with three low-level tools: move hand to(x, y, z) , set hand(closed) , get state() . It reasons through every step itself. - jev agent.py : Jev by TypeSafe, a "System One" model that answers typed questions with probabilities in a few hundred ms. Code proposes small moves and simulates each one ahead in a scratch copy of the physics; Jev picks the move, decides when to…
Getting started
sh nix develop Python 3.12 + uv (or bring your own Python 3.12 and uv) uv venv .venv && uv pip install --python .venv -r requirements.txt
- Languages
- Python 98% · Nix 2%
- License
- MIT
- Last activity
- Sep 2026
- Added
- 2026-09-23
- Stars at snapshot
- 0
- Status
- Recorded simulation demo
Source: Project README and source code. Details and metrics reflect the published community snapshot and are not a performance endorsement. Documentation details extracted from GitHub · the README.