jev-drone
Camera-only autonomous drone in MuJoCo with a small judgment model (TypeSafe Jev) in the loop at 2.5Hz
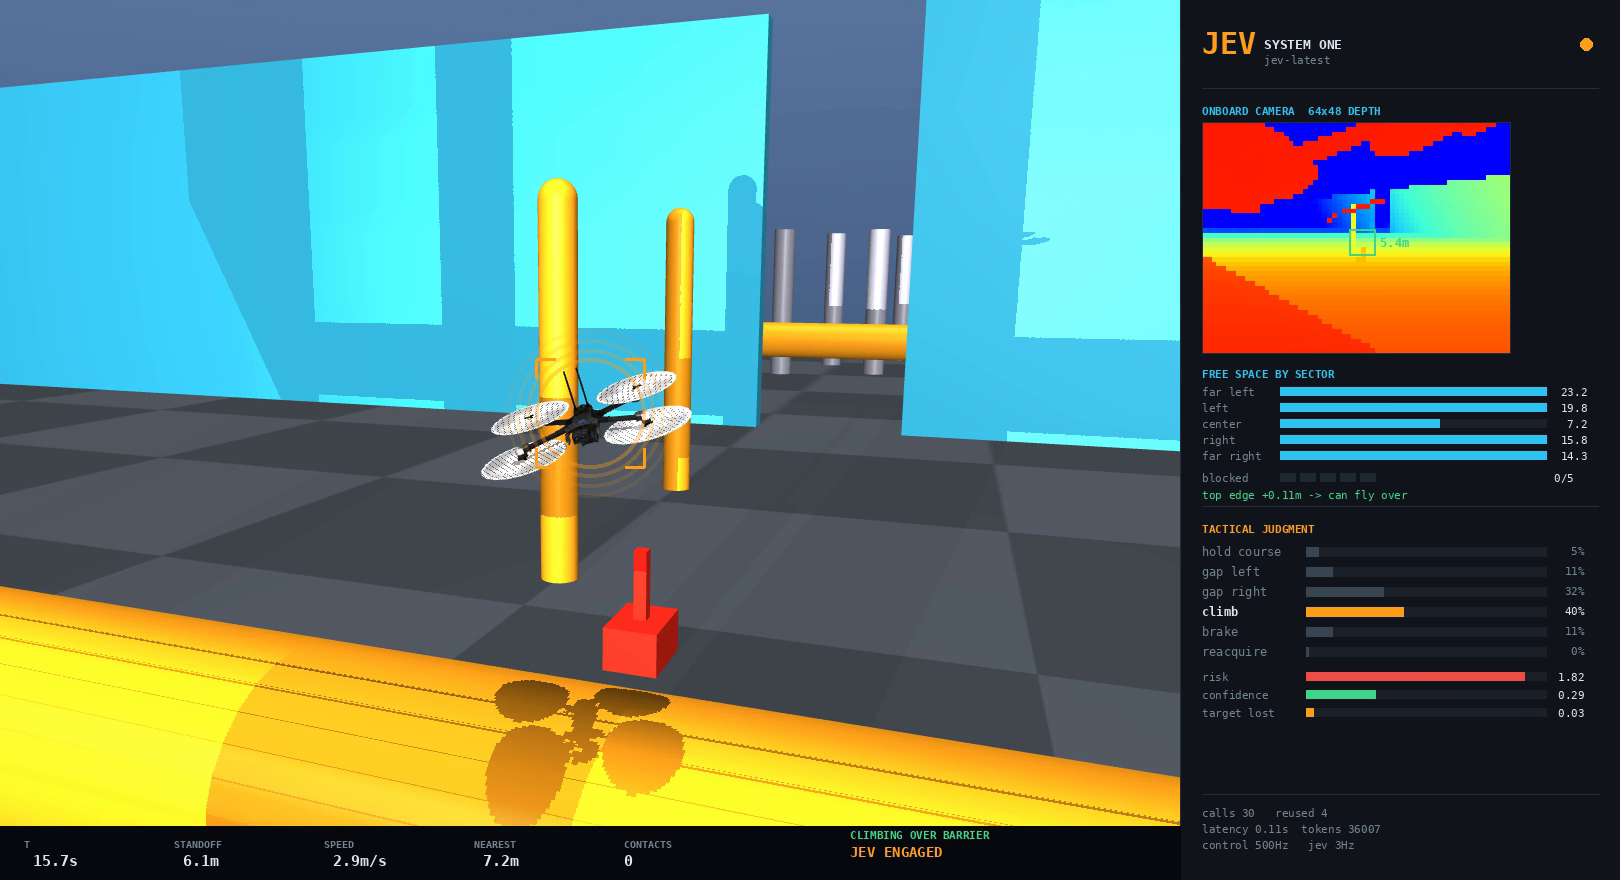
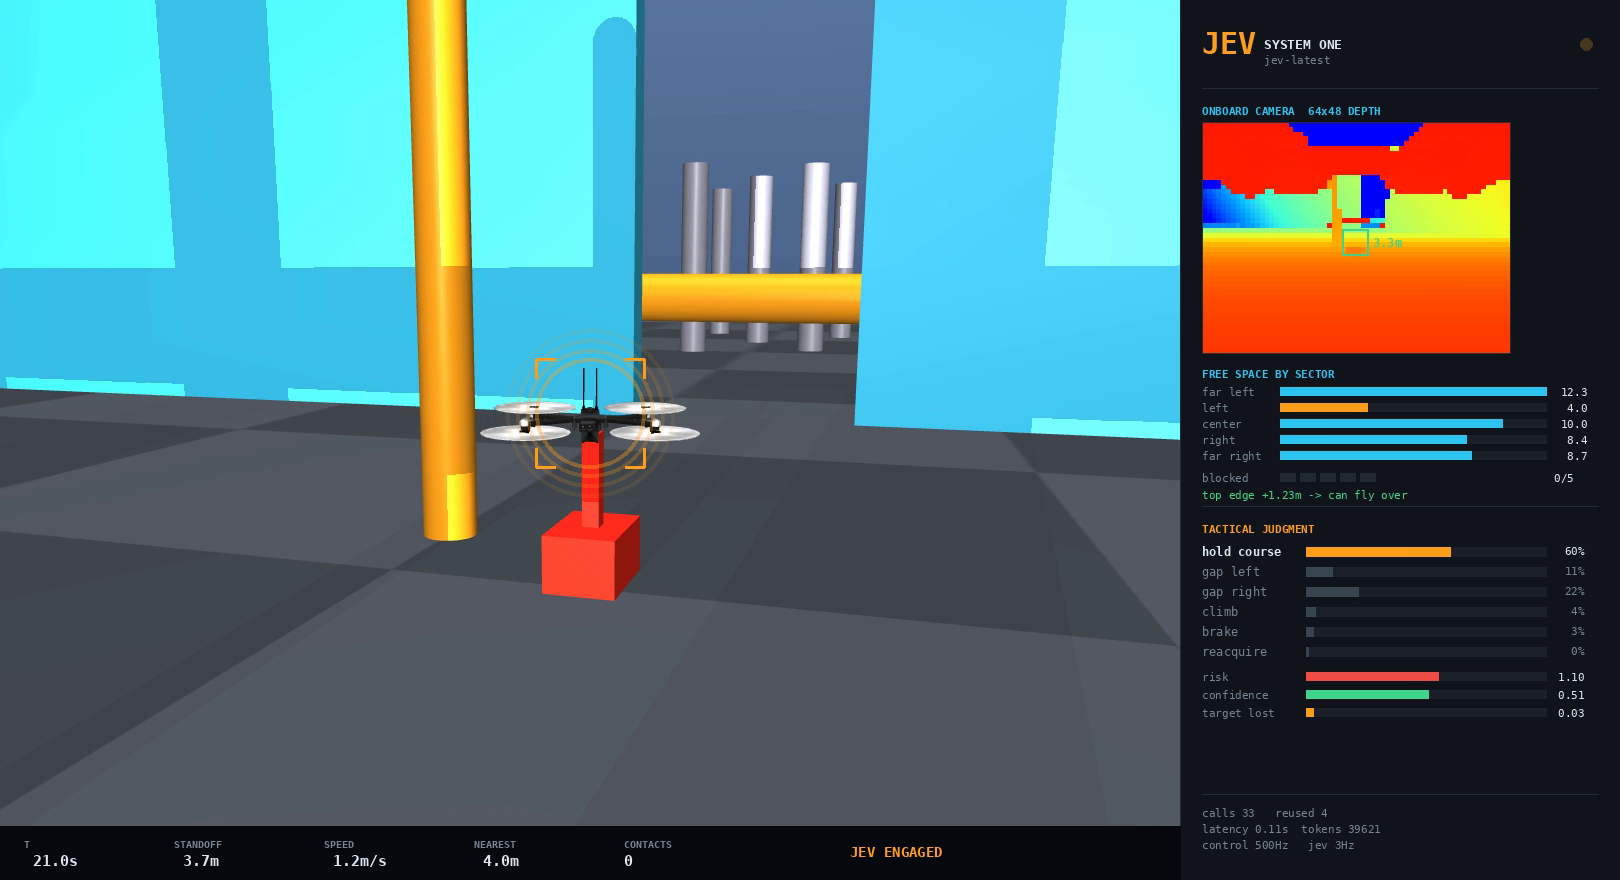
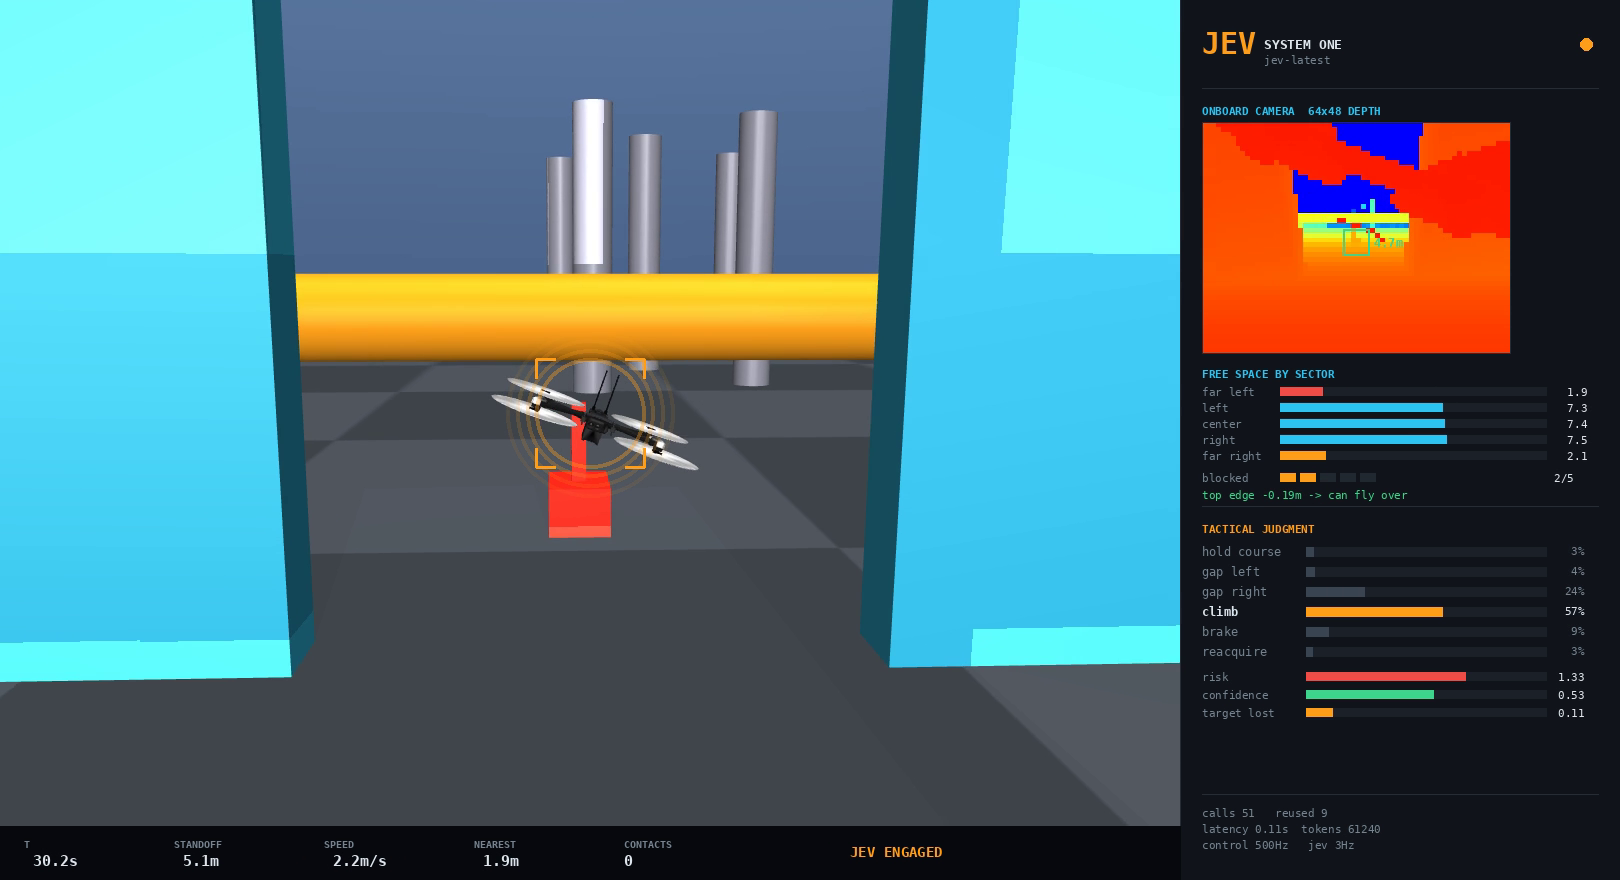
How it uses Jev
An autonomous quadrotor flies a five-station obstacle course in MuJoCo using only its onboard camera . A small judgment model (TypeSafe's Jev) sits at 2.5 Hz and decides what the situation means ; everything time-critical stays in ordinary code.
Source: community catalog. Details and metrics reflect the published community snapshot and are not a performance endorsement. Documentation details extracted from GitHub · the README · the project website.