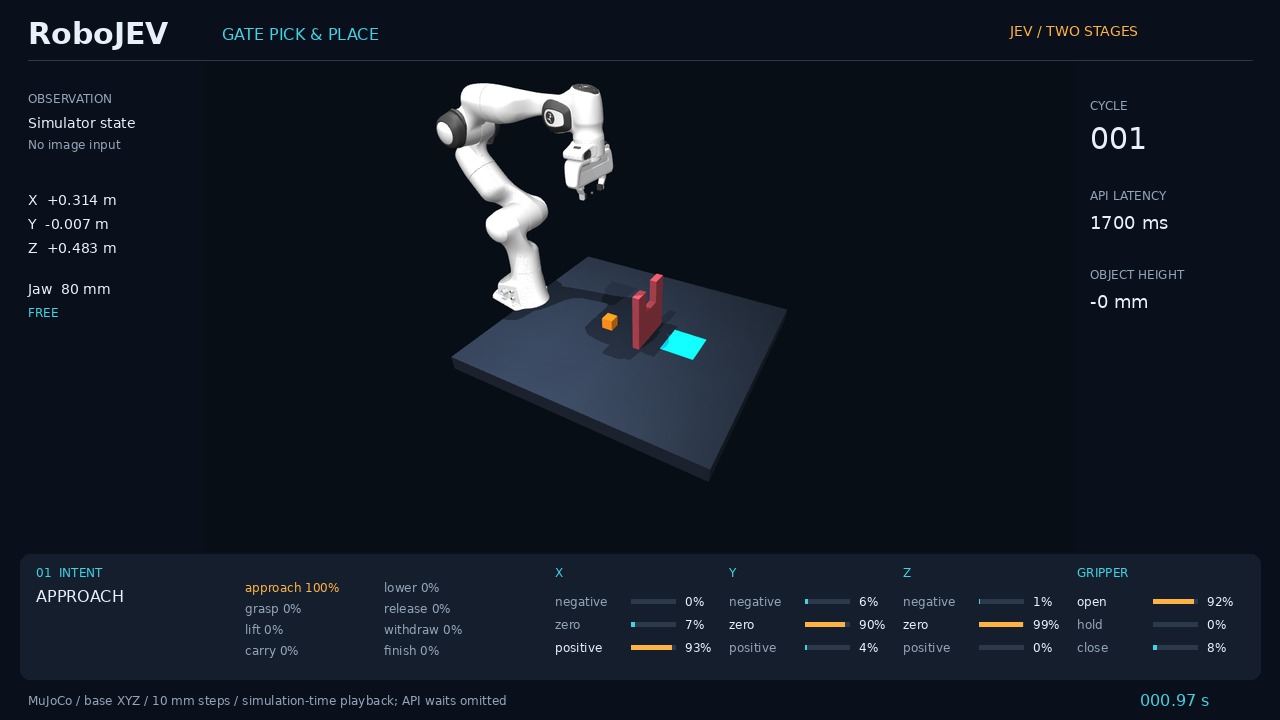
RoboJEV

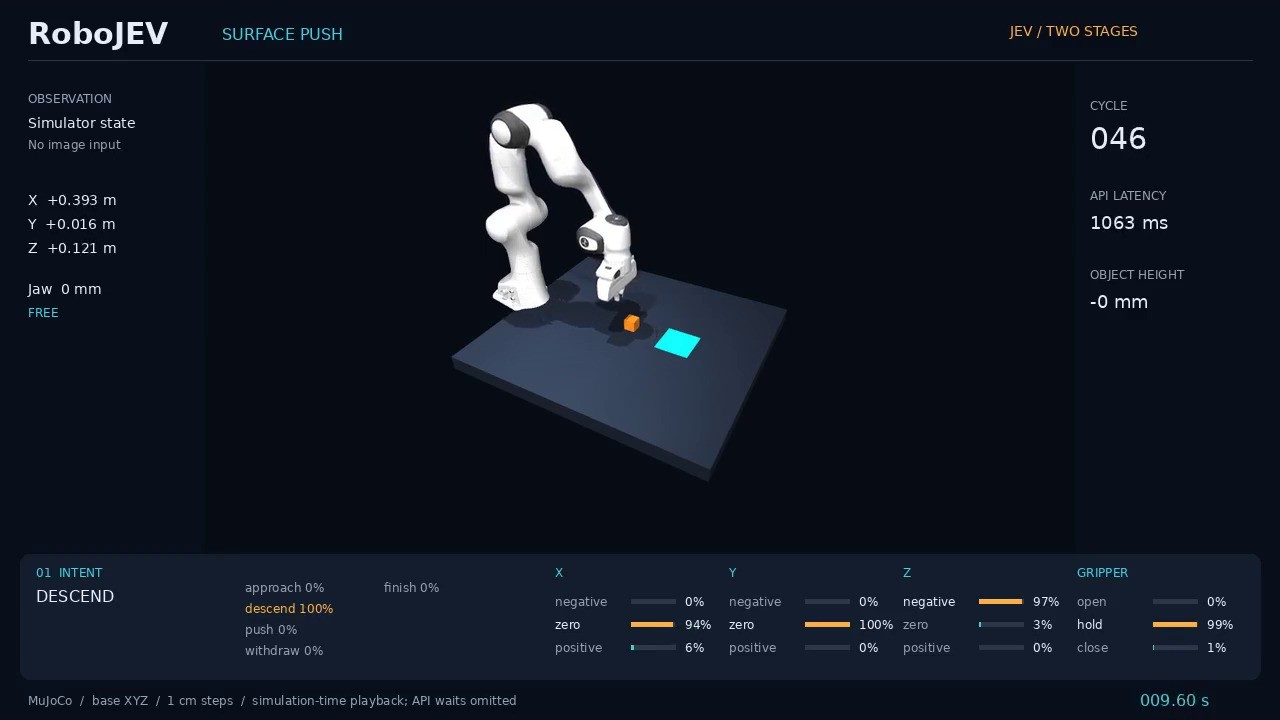
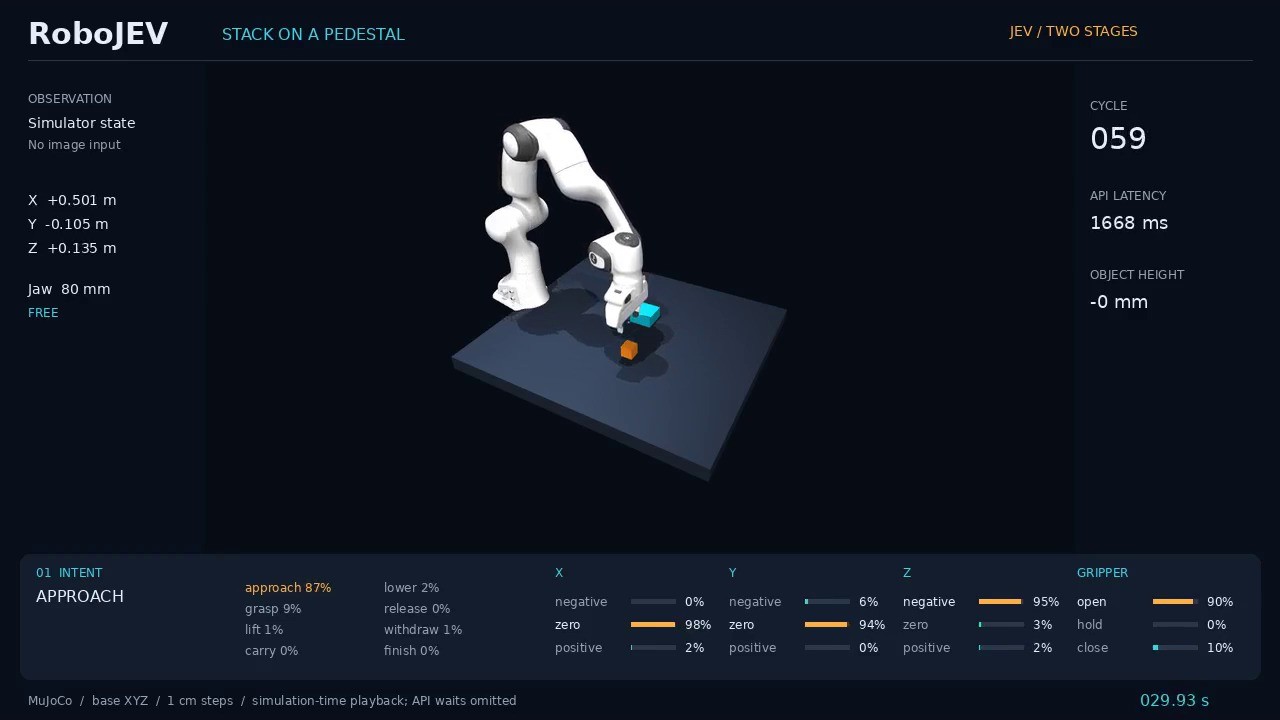
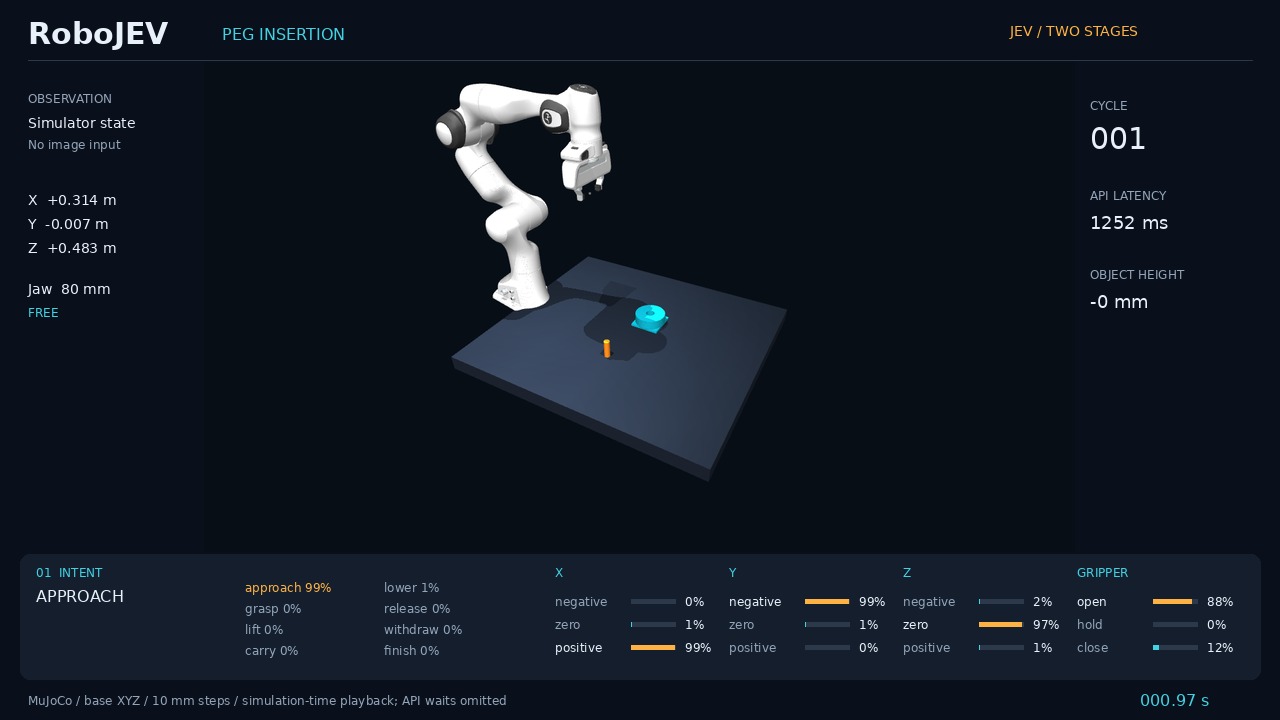
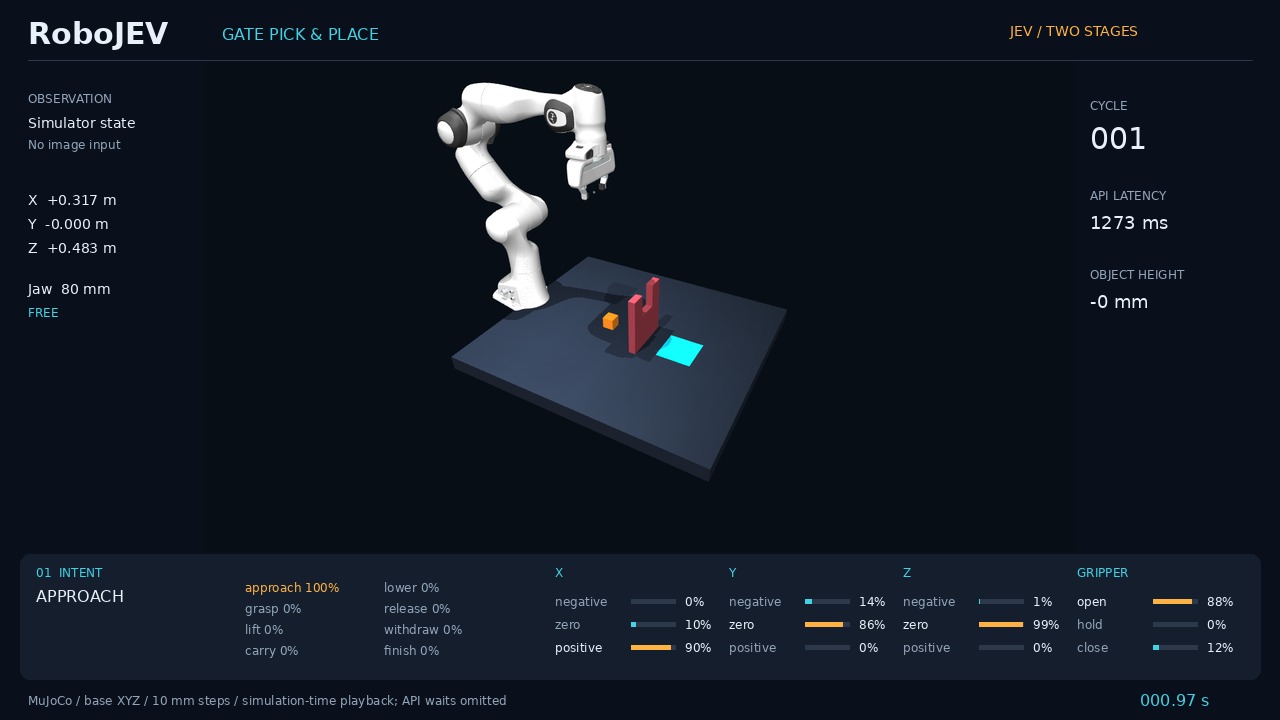
Two-stage JEV control of a Franka Panda in MuJoCo
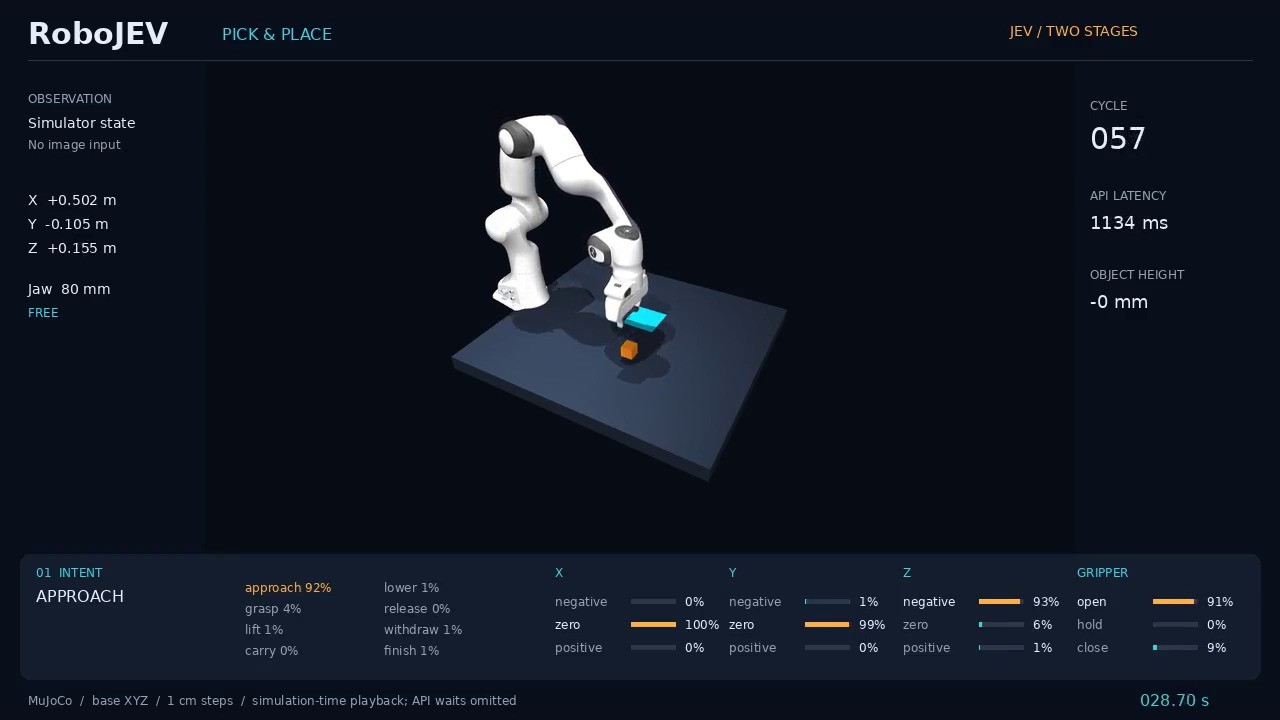
Getting started

Linux with Python 3.11 is the tested platform. CPU physics and the rule policy need no GPU or API key. A graphics backend is required only for recording.

Source: community catalog. Details and metrics reflect the published community snapshot and are not a performance endorsement. Documentation details extracted from GitHub · the README · the project website.
Keep exploring

Similar to RoboJEV

Browse all
jev-askable-arm project preview
Games & simulations
Zero-shot English goals on a sim Franka. Jev chains hardcoded primitives.
tsai-sc project preview
Games & simulations
TypeSafe Jev controls original StarCraft shareware through keyboard and mouse with recorded action probabilities.
DoomSat project preview
Games & simulations
F´ flight software → CCSDS/Yamcs → Open MCT, with jev (System One) and Claude Sonnet 5 (System Two) driving Doom over that real mission stack.
mcpmatch project preview
Demos & playgrounds
Match user goals to MCP catalog (two-stage) via TypeSafe Jev
Jev vs LLM robot arm project preview
Jev for robotics
A simulated Franka arm stacks cubes in MuJoCo. Code previews candidate moves in physics; Jev chooses a move and judges grasp, release, and completion. The README reports one recorded run for each controller.
jevframe project preview
Demos & playgrounds
Semantic AI for pandas and Polars: classify text, analyze sentiment, and score DataFrame rows with natural-language questions and full probabilities using TypeSafe Jev.
Jev for robotics
Camera-only autonomous drone in MuJoCo with a small judgment model (TypeSafe Jev) in the loop at 2.5Hz
Jev for robotics
EmbodiedJev: MuJoCo robot decision workbench with MiniCPM5-2B, Jev and compatible model APIs
git-jev-stage project preview
Agent tooling
Select Git changes for staging with a plain-language description.