embodied-jev

EmbodiedJev: MuJoCo robot decision workbench with MiniCPM5-2B, Jev and compatible model APIs
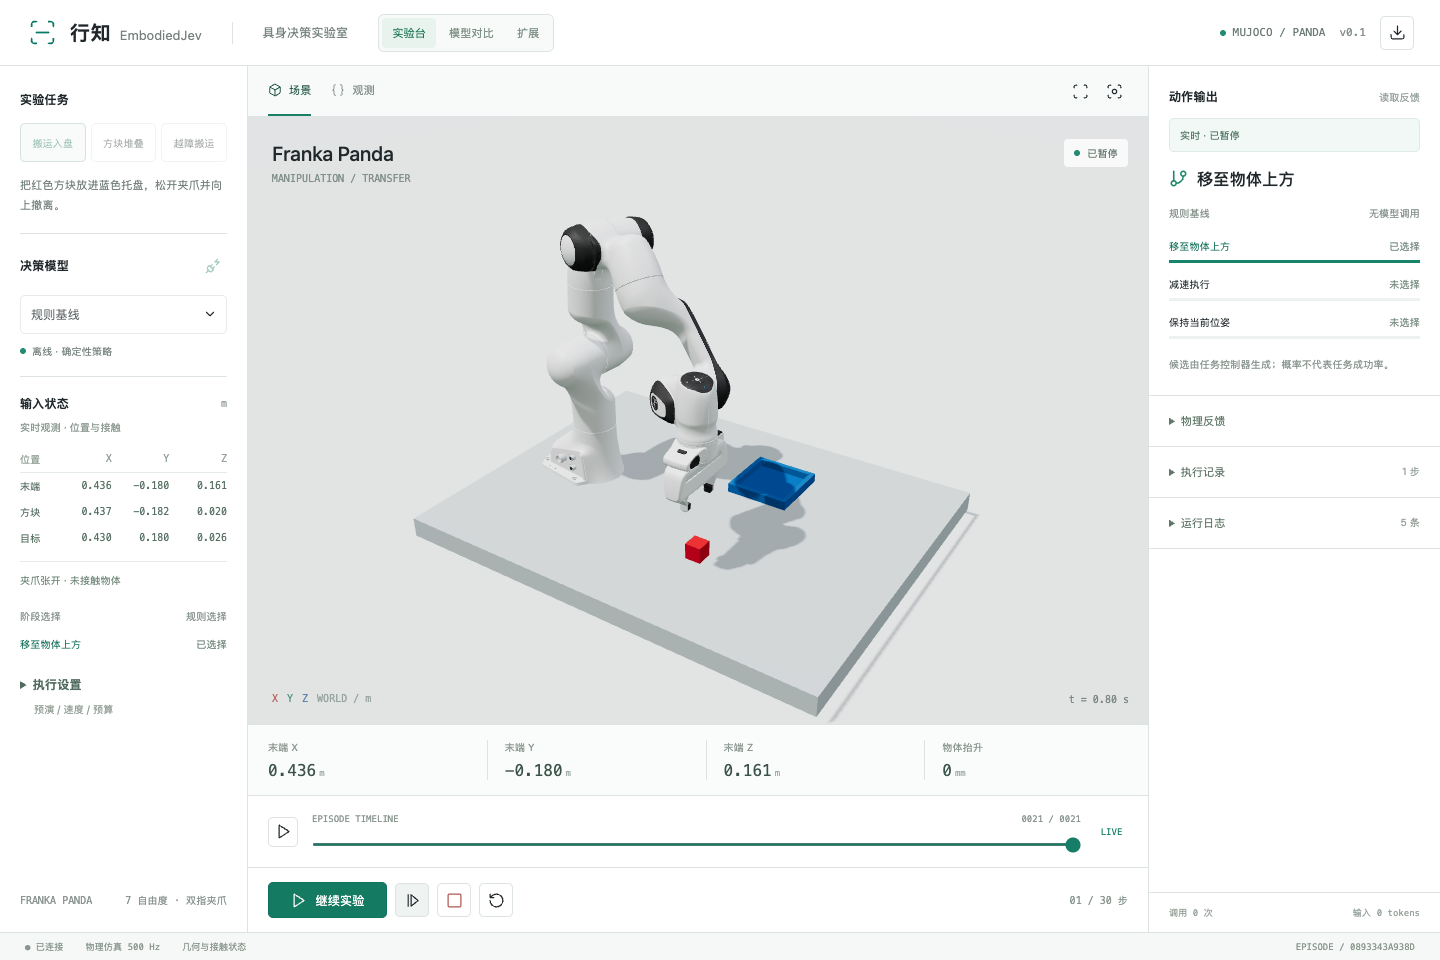
embodied-jev project preview

How it uses Jev

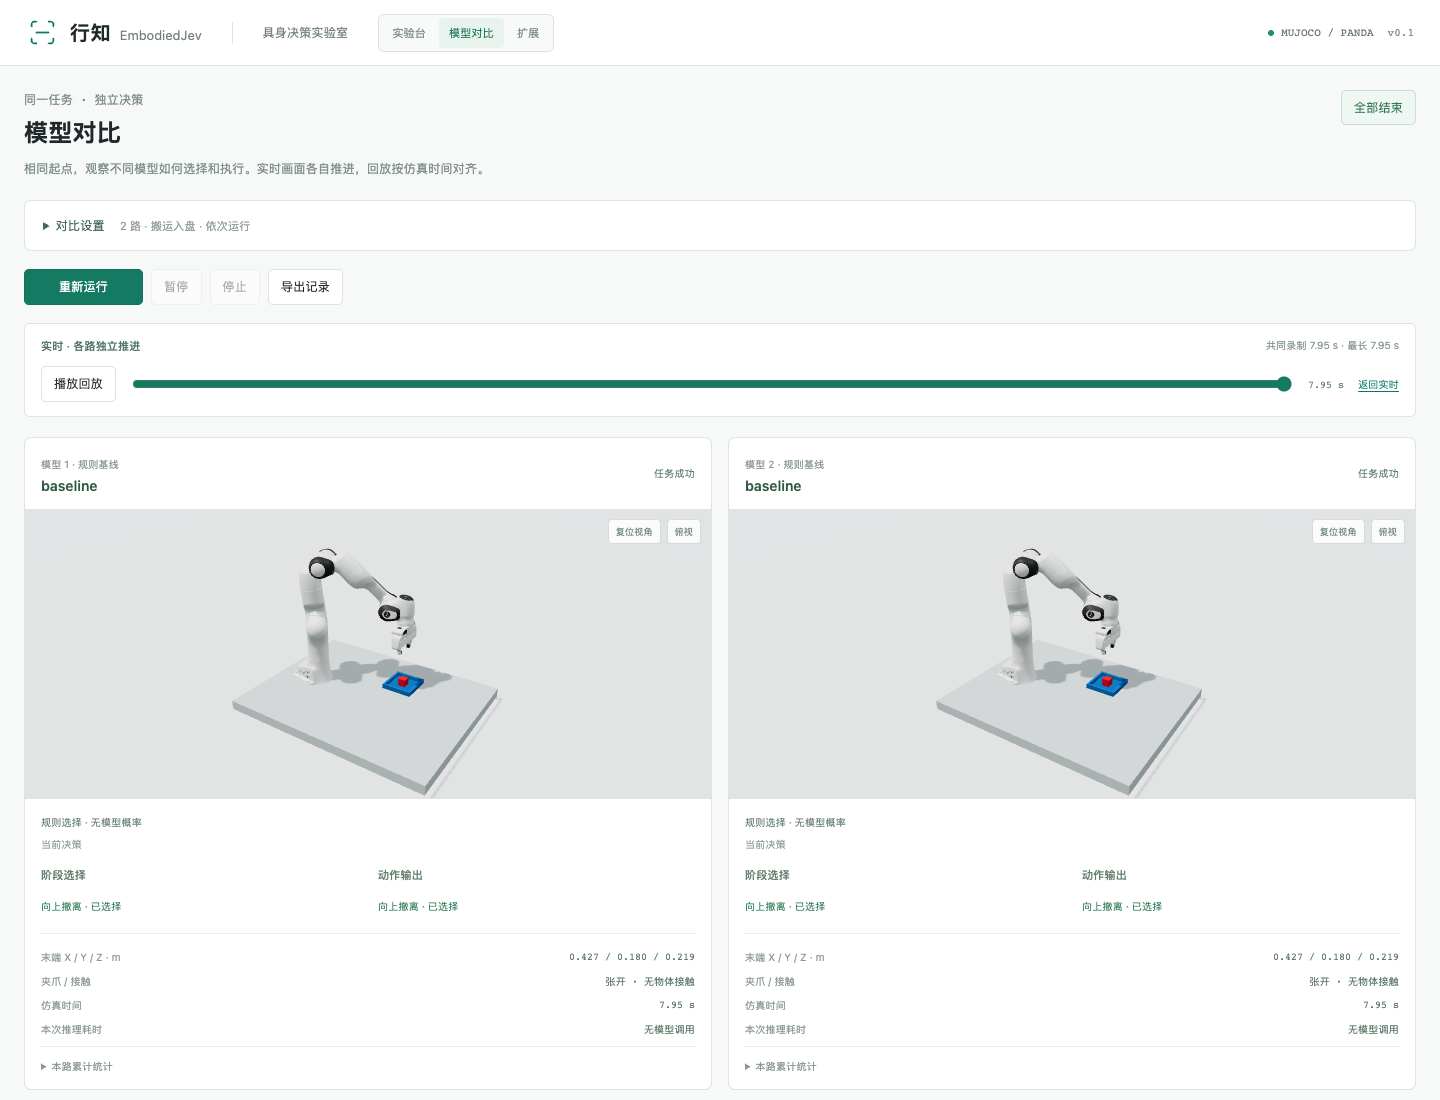
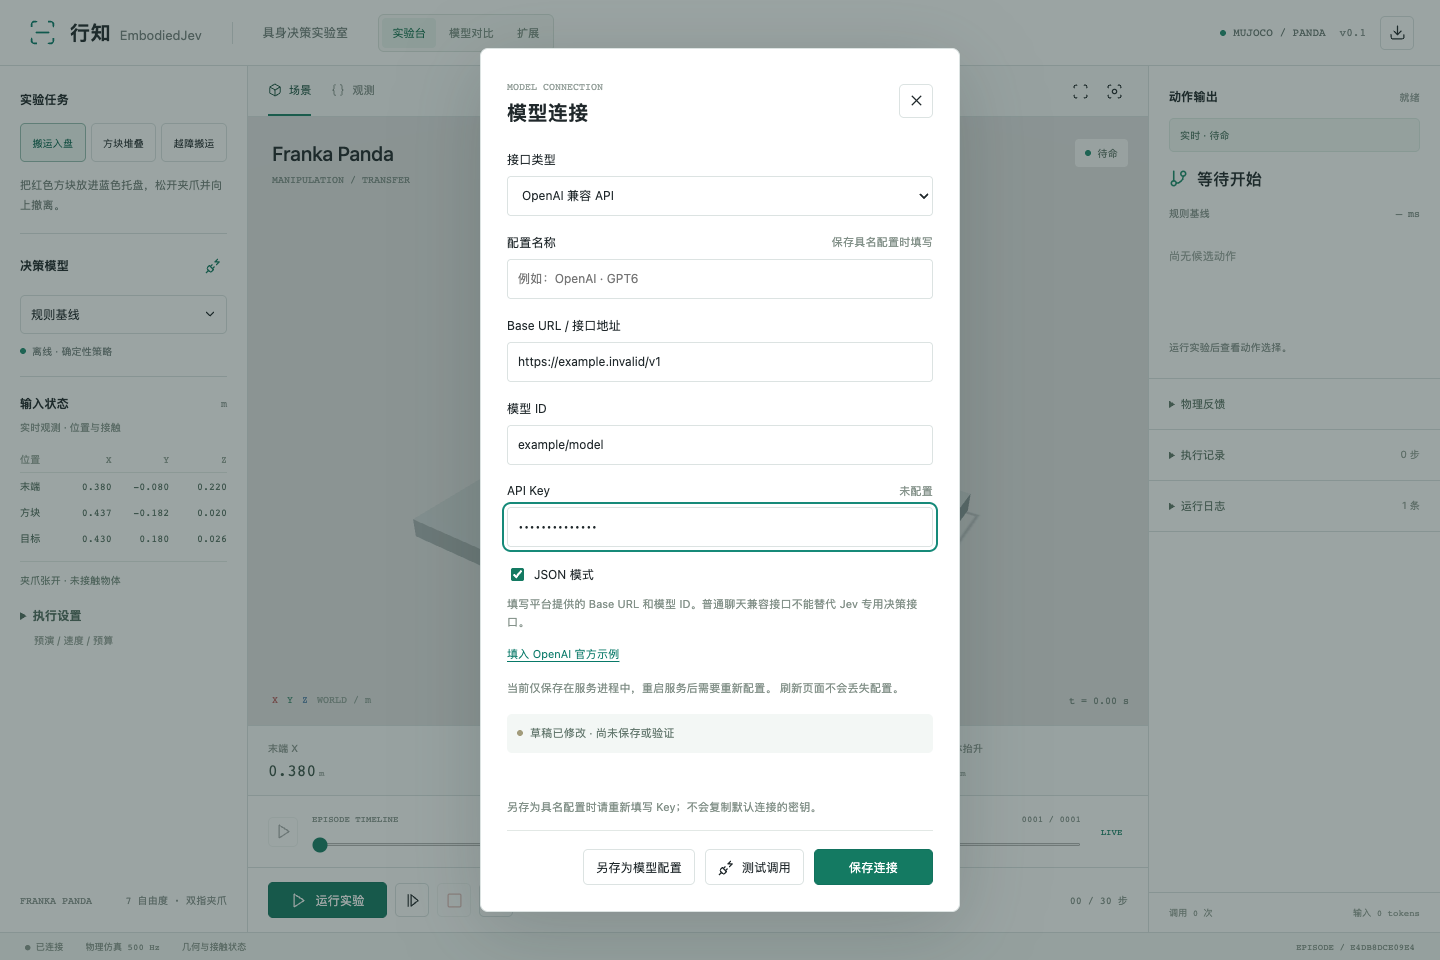
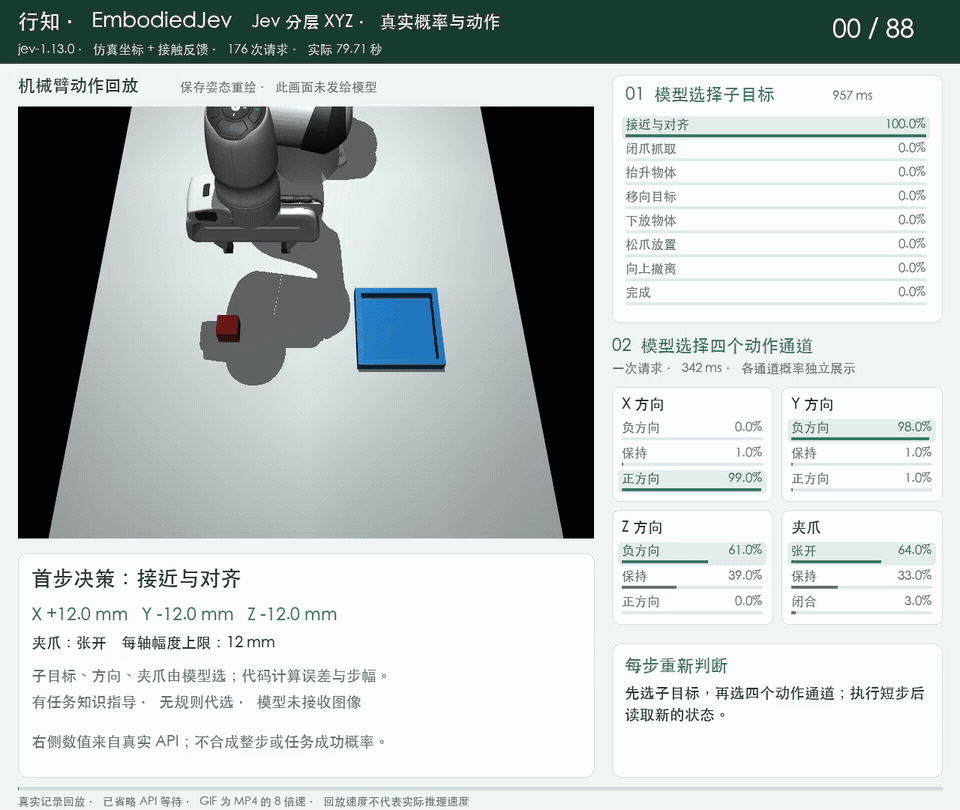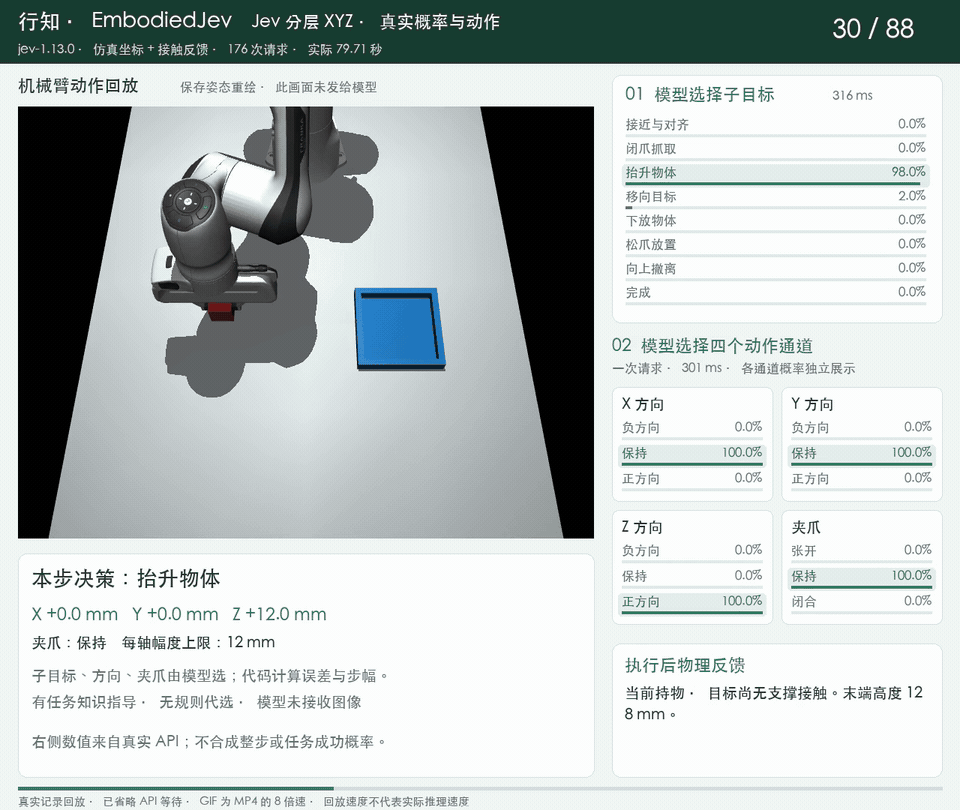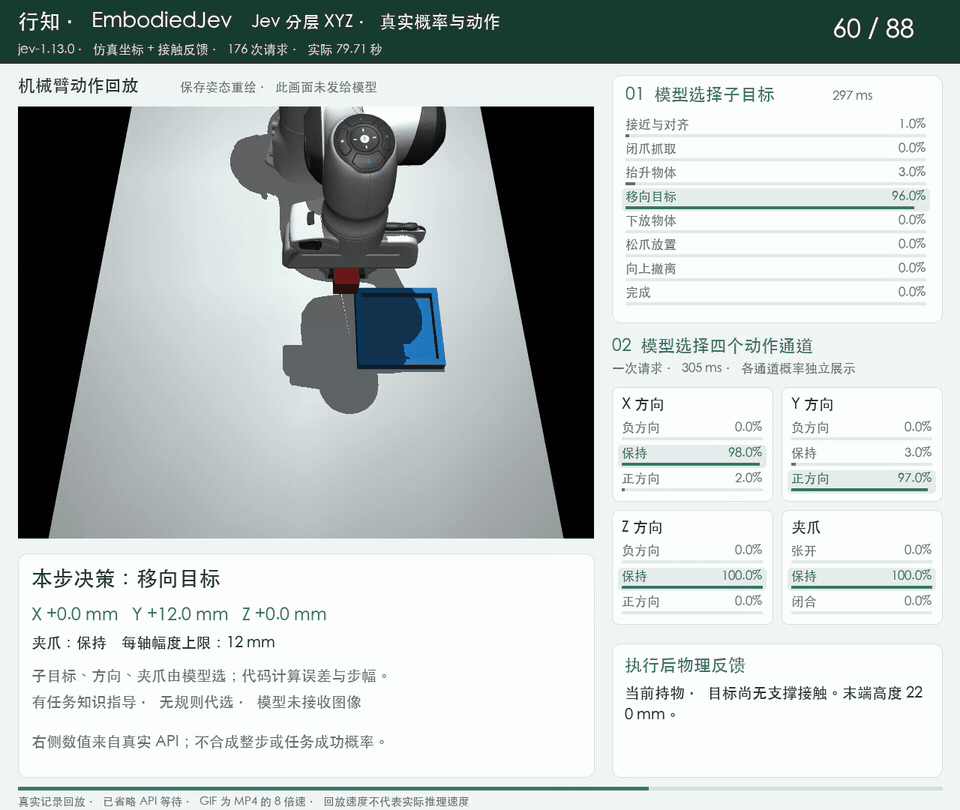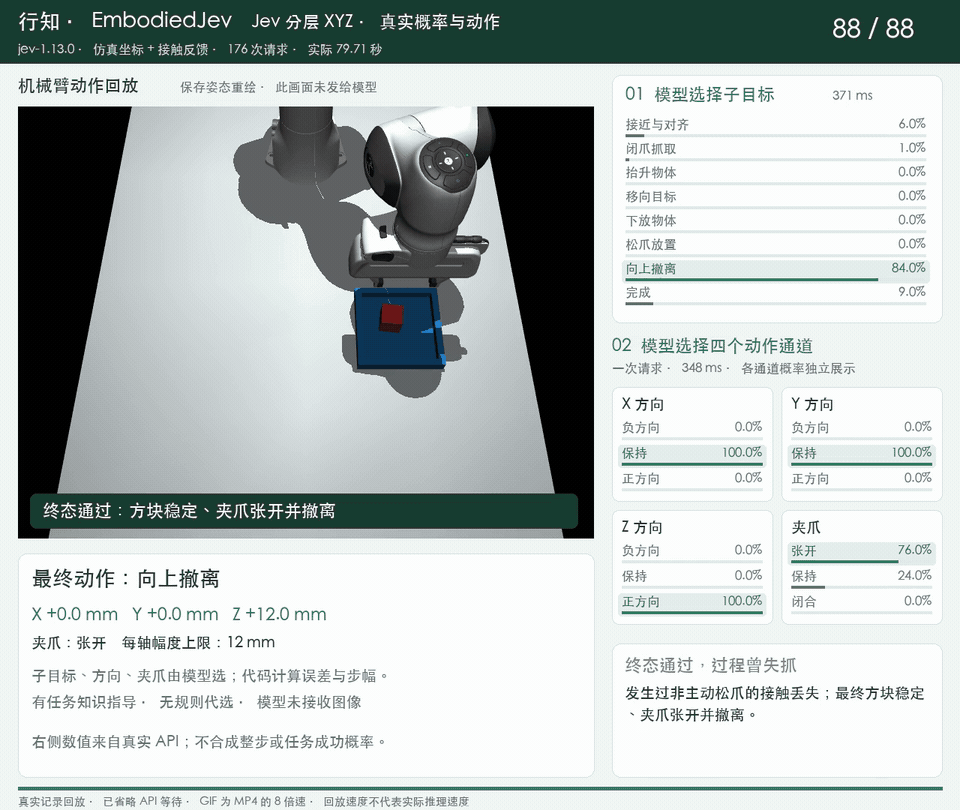
- 📦 先玩起来,再接模型 :内置规则基线,无需 API Key、GPU 或模型权重,即可运行三个任务。首次安装依赖需要联网。 - 🦾 真实物理交互 :MuJoCo + Franka Panda,夹爪接触、抓取、搬运和放置都有物理反馈。 - 🧠 模型入口放在界面里 :可接 TypeSafe Jev、Claude 原生 API、OpenAI 兼容 API,以及本地 MiniCPM5-2B。 - 👀 决策过程看得见 :查看阶段或短步选择、公开的动作说明、调用次数与延迟;有原生候选概率的接口还会显示概率。 - 🧭 逐步规划也能试 :模型逐轮选择 XYZ 方向、步长和夹爪动作,执行后重新观测;可用原始图像输入并加入中途扰动。 - 📷 相机自由组合 :仅外部、仅腕部、双相机或无相机;启用的视角按动作边界更新,腕部相机随手移动。 - 🆚 同一任务,不同模型 :可选 2–3 路独立实验,统一任务和种子,真实运行后按仿真时间对齐…

Source: community catalog. Details and metrics reflect the published community snapshot and are not a performance endorsement. Documentation details extracted from GitHub · the README.
Keep exploring

Similar to embodied-jev

Browse all
Jev for robotics
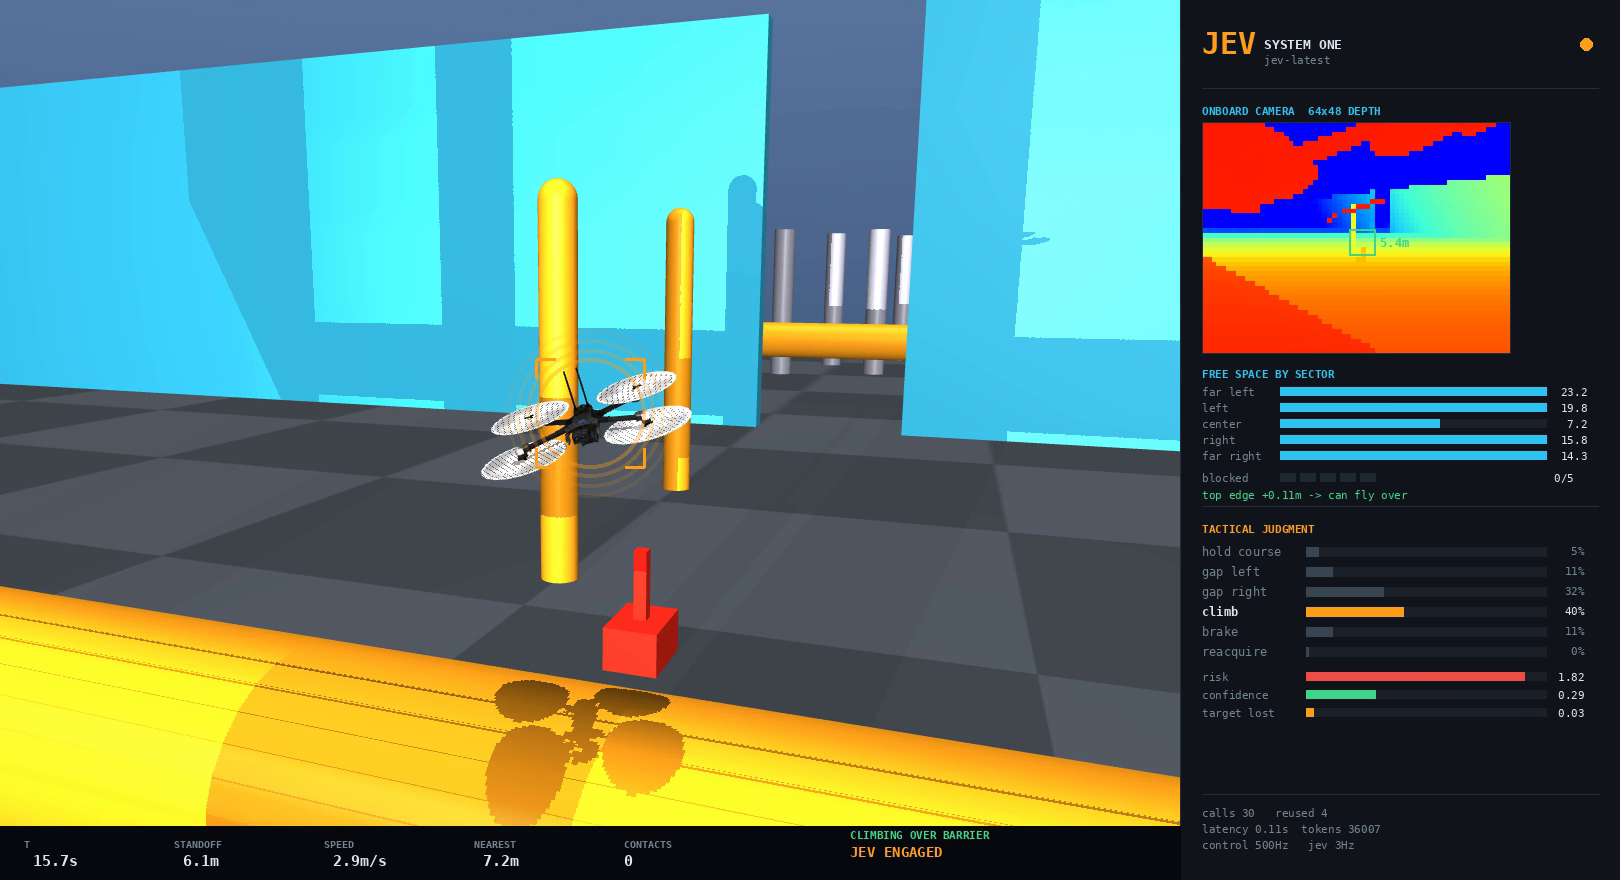
Camera-only autonomous drone in MuJoCo with a small judgment model (TypeSafe Jev) in the loop at 2.5Hz
Jev vs LLM robot arm project preview
Jev for robotics
A simulated Franka arm stacks cubes in MuJoCo. Code previews candidate moves in physics; Jev chooses a move and judges grasp, release, and completion. The README reports one recorded run for each controller.
Jev for robotics
Fine-grained robot control with Jev, physics previews, and configurable LIBERO tasks.
System One adapter (Python) project preview
Official drop-in TypeSafeClient replacement backed by OpenAI, Anthropic, and compatible LLM APIs, for comparing Jev against chat models.
RoboJEV project preview
Games & simulations
Two-stage JEV control of a Franka Panda in MuJoCo
jev-docs project preview
SDKs & clients
Community-maintained history of Jev / TypeSafe System One APIs, SDKs, agent guidance, and engineering best practices.
jev-dataops project preview
Benchmarks & research
An open-source JEV-powered workbench for streaming data selection, quality evaluation, automatic LoRA training and held-out model evaluation.
openjev project preview
Benchmarks & research
Open, Jev-compatible System One decision server on DiffusionGemma
jev-pick-and-place-study project preview
Benchmarks & research
A small reproducible MuJoCo pilot comparing Jev, Claude Haiku, and reactive rules for pick-and-place.