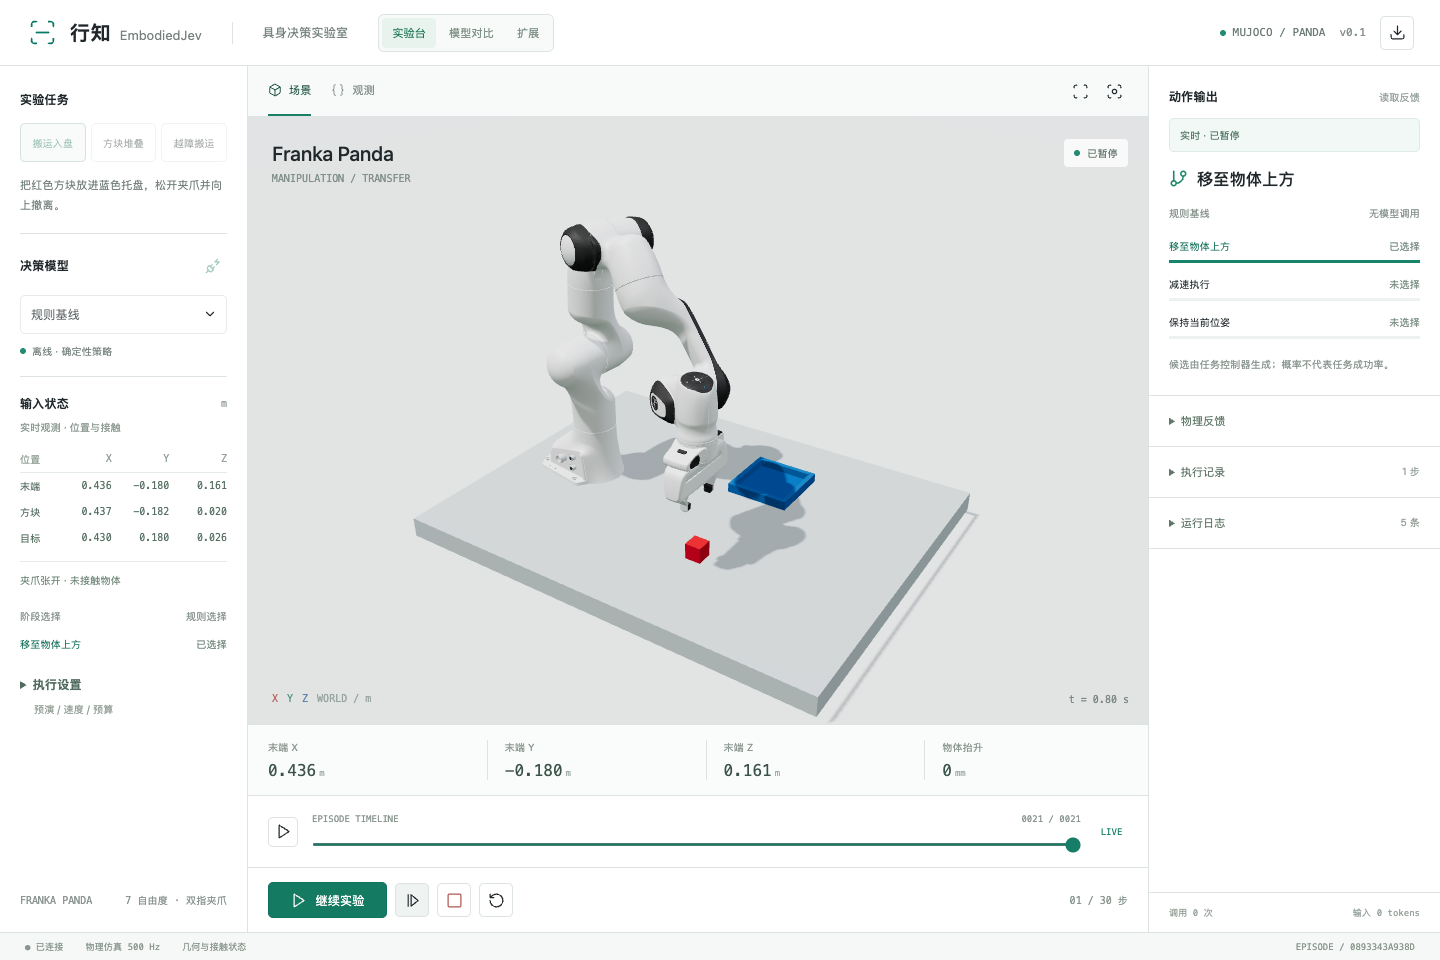
jev-libero
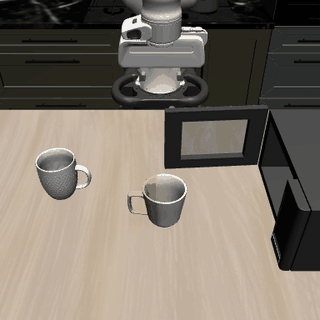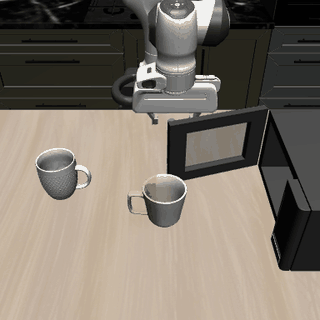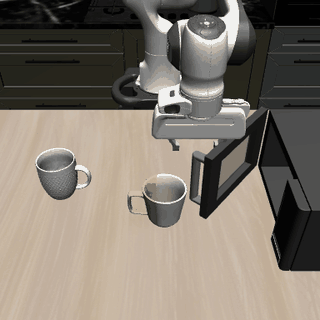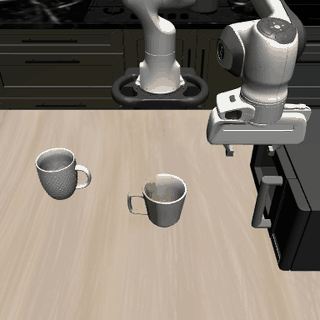
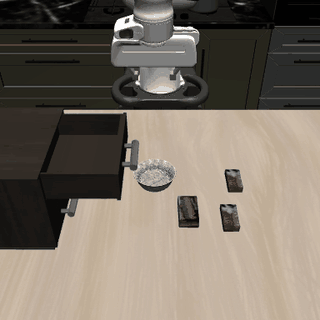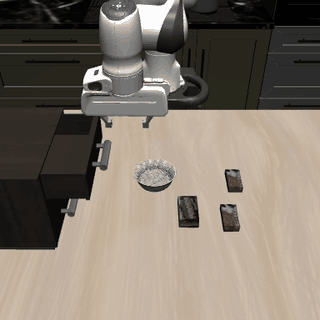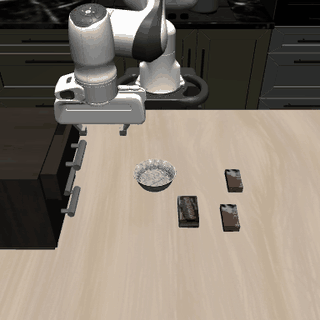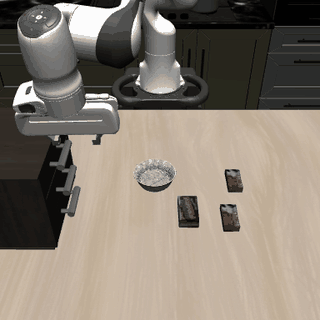
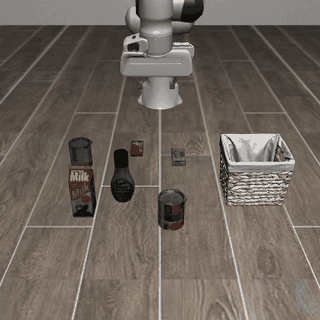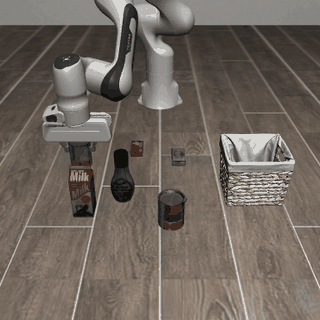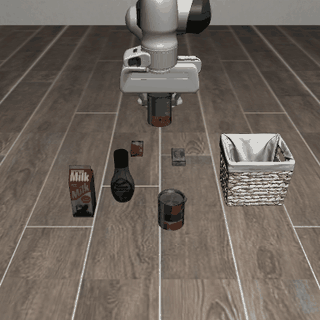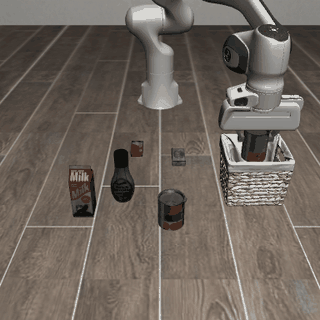
Fine-grained robot control with Jev, physics previews, and configurable LIBERO tasks.
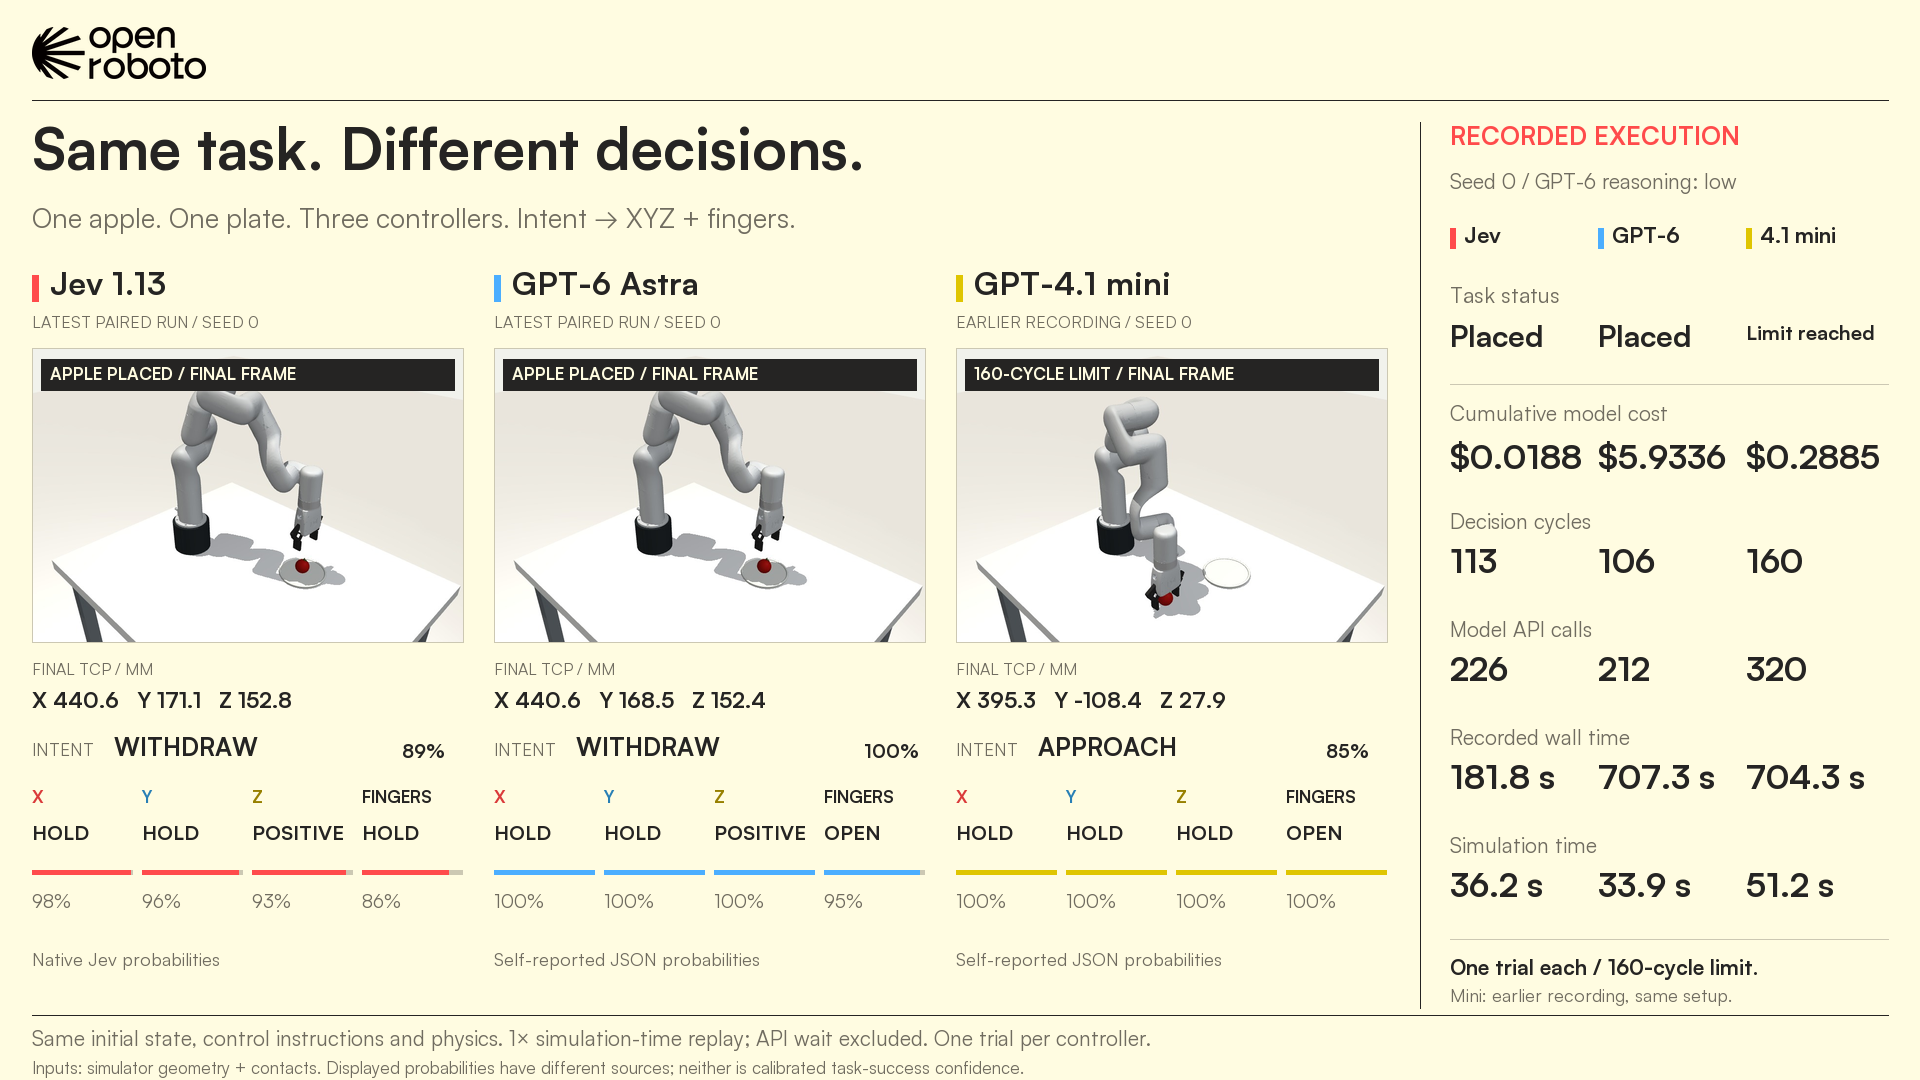
How it uses Jev
Explore robot control with Jev, local physics previews, and configurable tasks.
Highlights
- Fine-grained control. 27 inputs covering Cartesian translations, wrist rotations, gripper open/close, and hold.
- Layered decisions. Jev selects an intent, a contact/motion family, and an input, with each choice informing the next.
- Local physics previews. Reversible simulator branches evaluate candidate effects before execution.
- Configurable tasks. Select measurements, exported features, contact rules, goals, and per-layer Jev inputs in JSON through one shared interface.
- Inspectable runs. Save model requests, predictions, controls, simulator states, costs, and trajectory media together.
Getting started
Use Python 3.10 or 3.11 in your preferred environment:
Source: community catalog. Details and metrics reflect the published community snapshot and are not a performance endorsement. Documentation details extracted from GitHub · the README · the project website.