Jev robot control
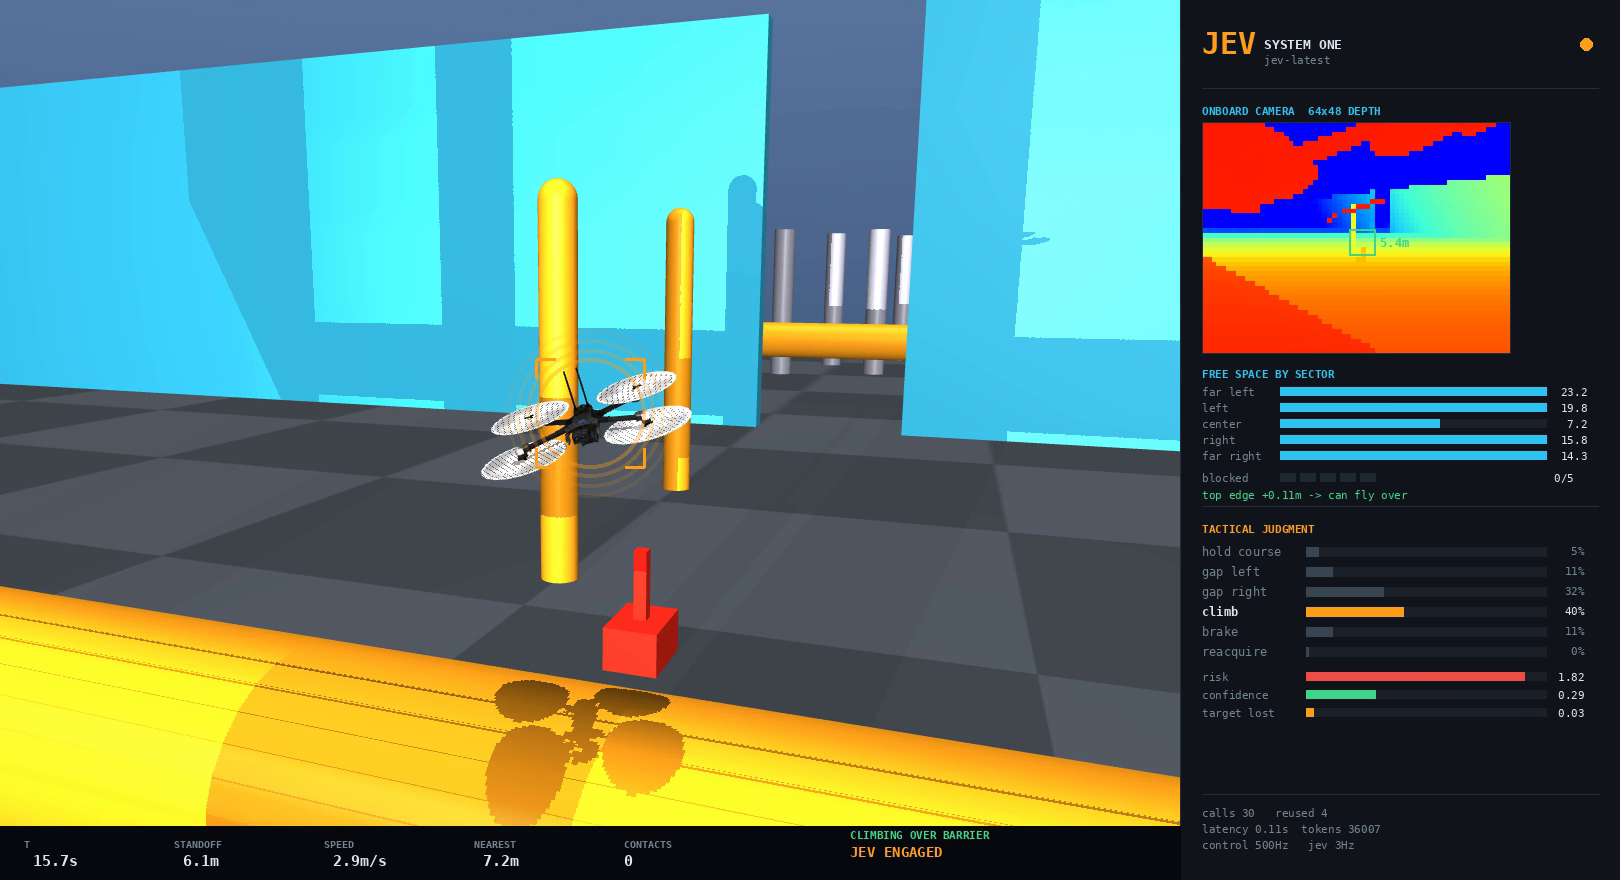
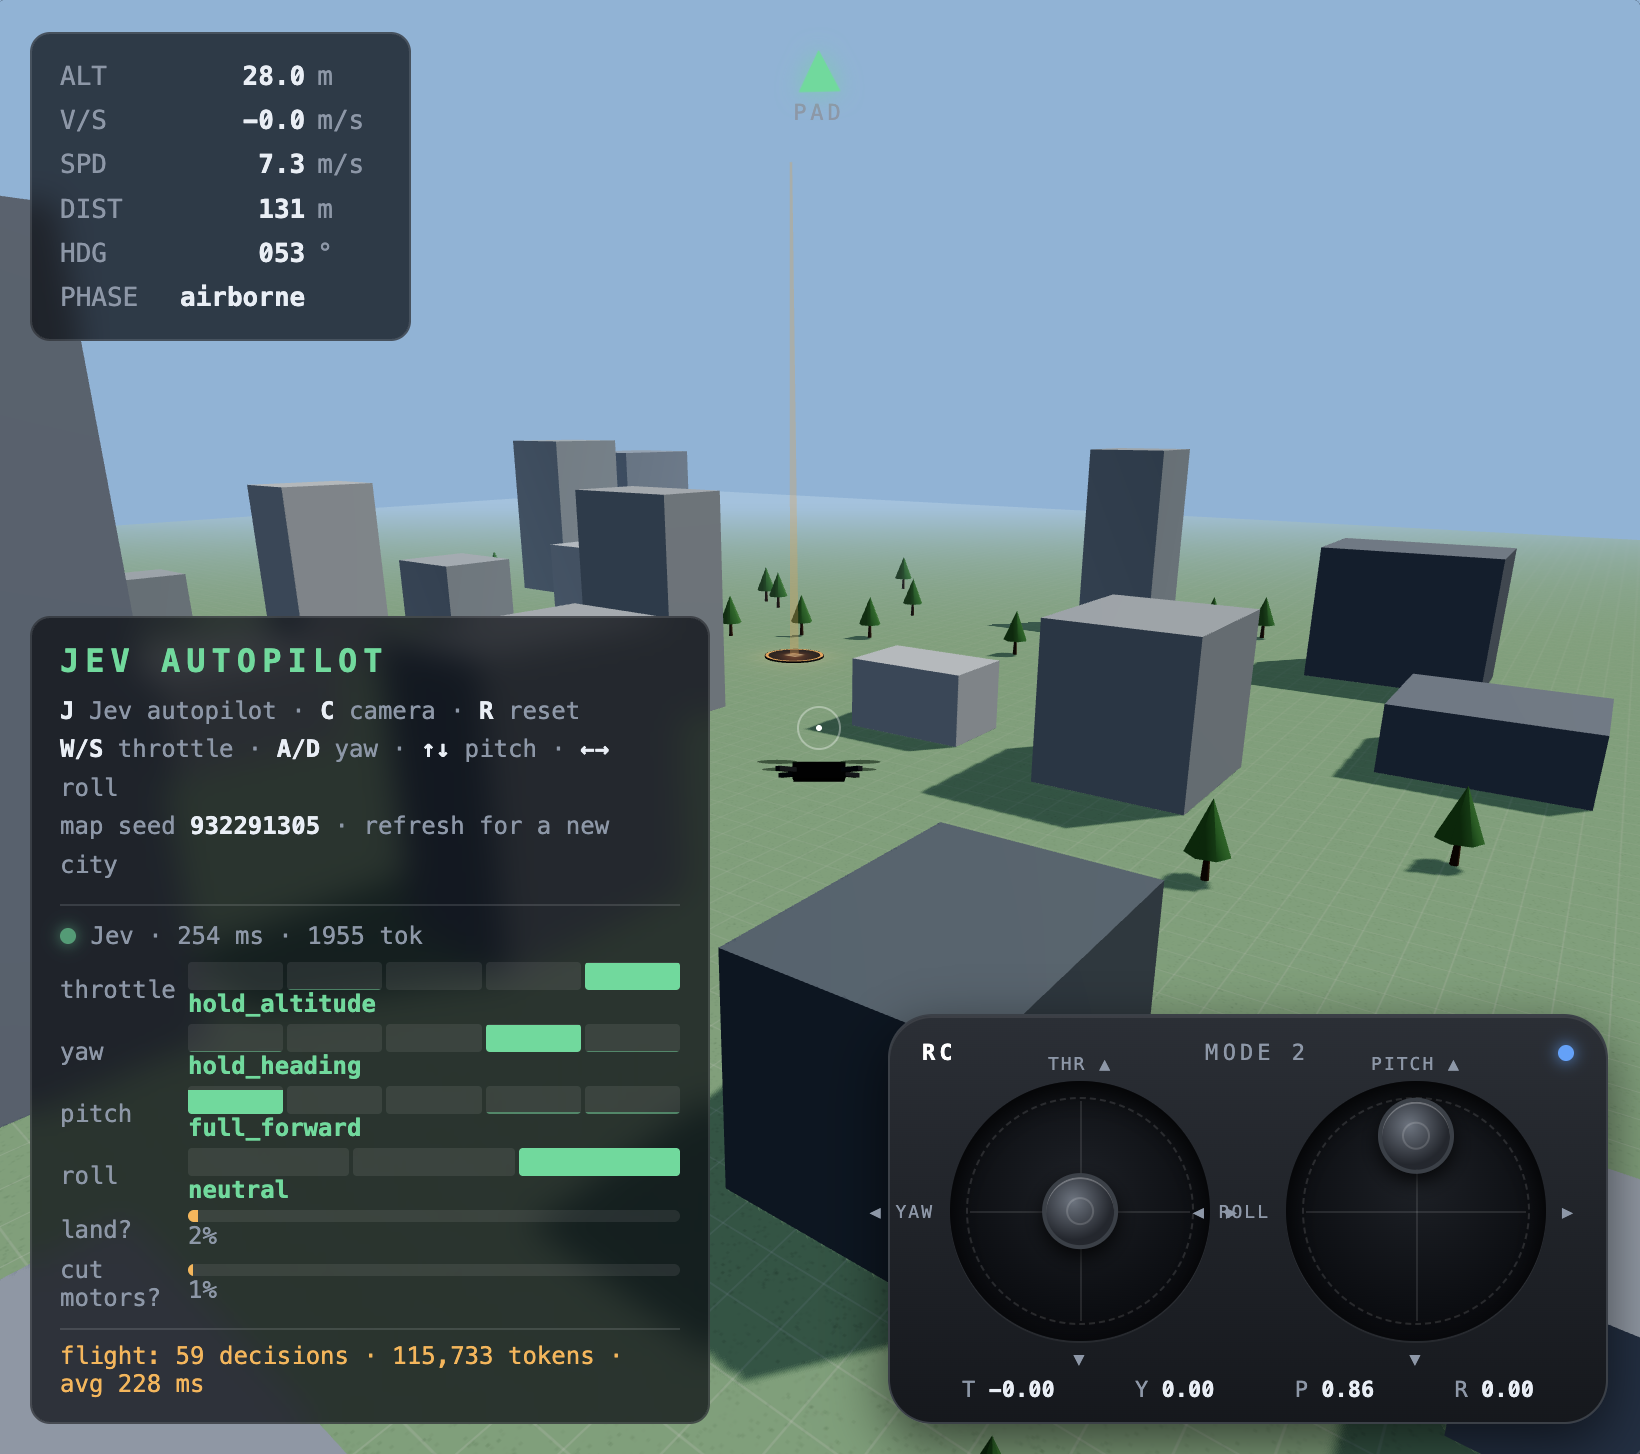
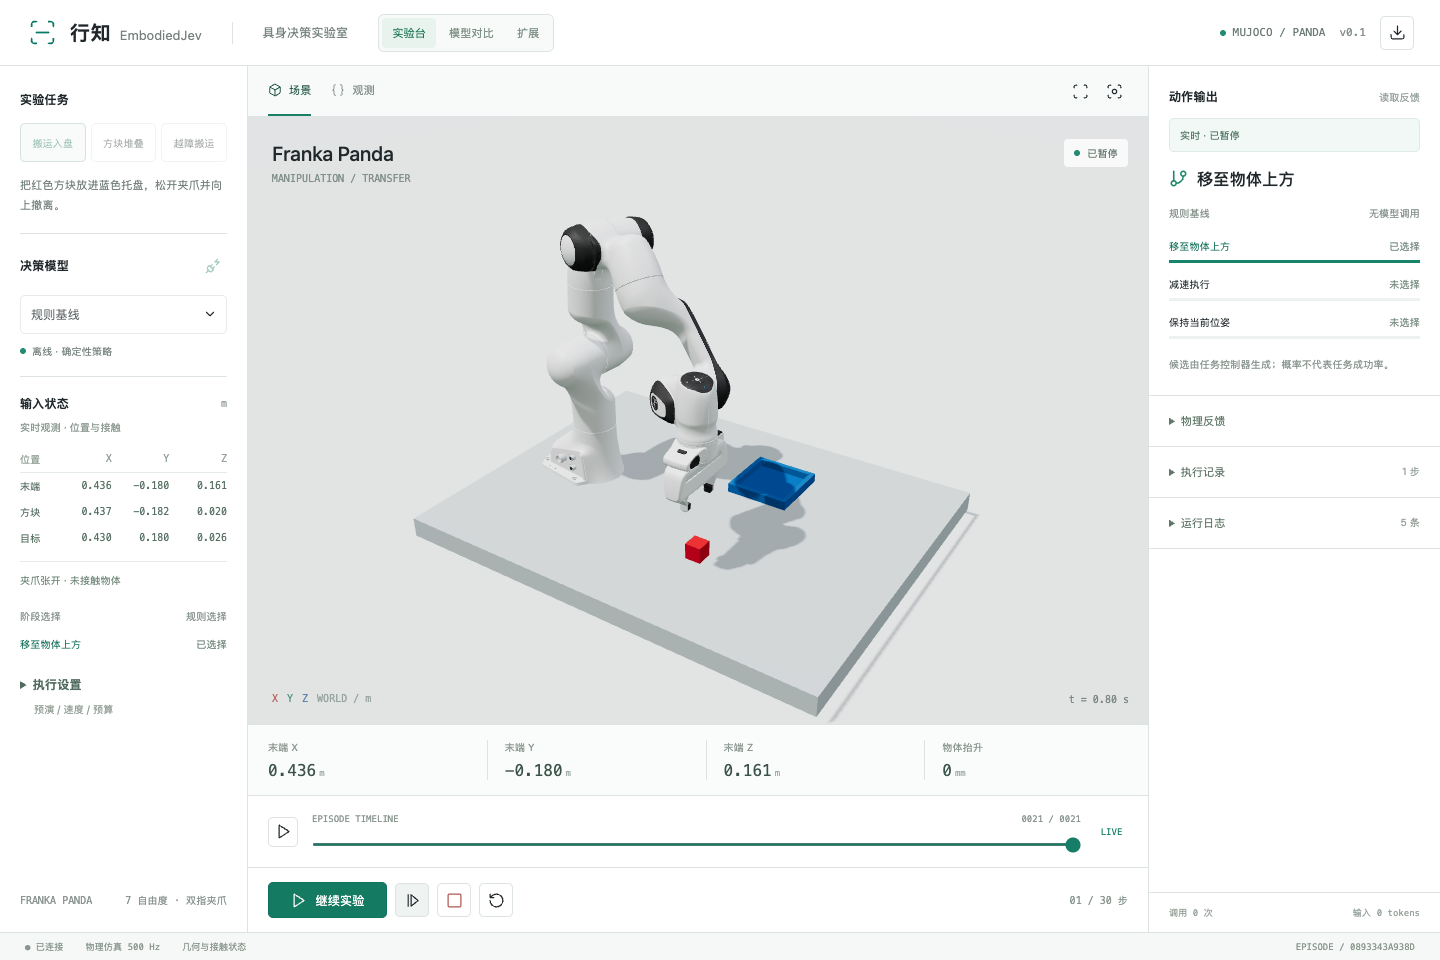
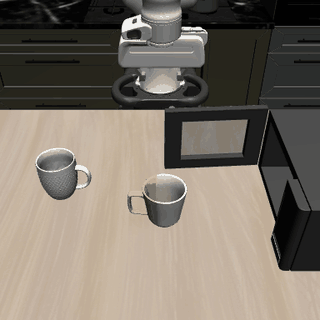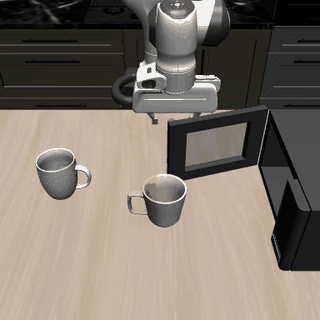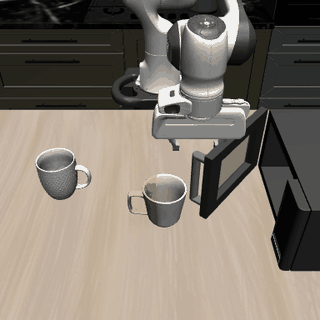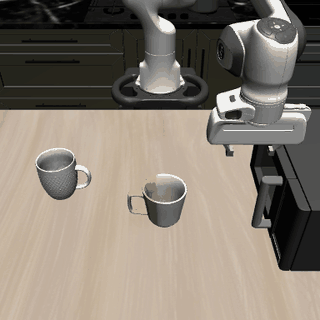
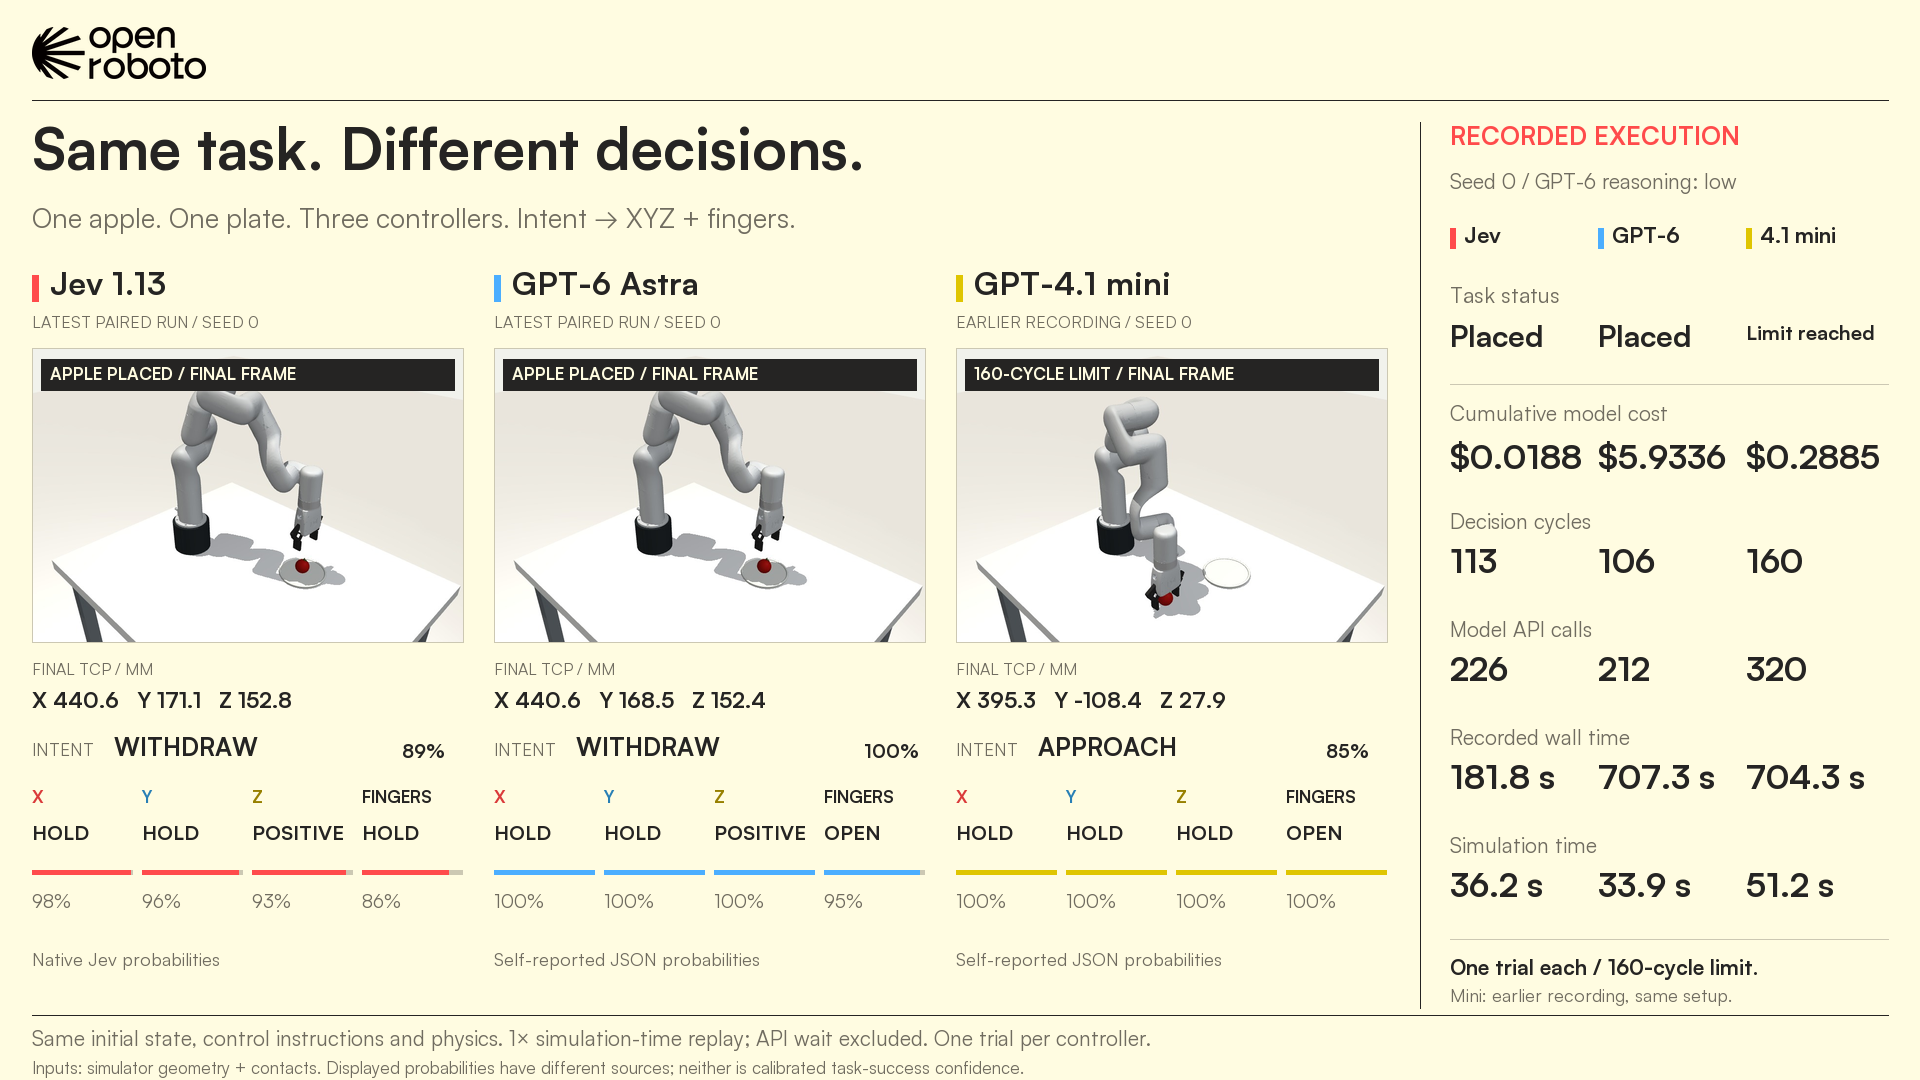
A MuJoCo xArm7 pick-and-place experiment. Jev selects an intent and bounded Cartesian directions; the shared controller applies motion and checks physical feedback. The published comparison is one recorded trial per controller, not a success-rate benchmark.
Jev vs GPT-6 Astra vs GPT-4.1 mini: direct Cartesian control of an xArm7 in MuJoCo.
How it uses Jev
Jev vs GPT-6 Astra vs GPT-4.1 mini: direct Cartesian control of an xArm7 in MuJoCo.
- Languages
- Python 79% · HTML 21%
- License
- NOASSERTION
- Last activity
- Sep 2026
- Added
- 2026-09-23
- Stars at snapshot
- 0
- Status
- Recorded simulation experiment
Source: Project README and recorded trajectories. Details and metrics reflect the published community snapshot and are not a performance endorsement. Documentation details extracted from GitHub · the README.