jev-reflex-autonomy-lab

Multi-drone autonomy lab demonstrating TypeSafe Jev reflex decisions with optional System 2 strategy guidance.
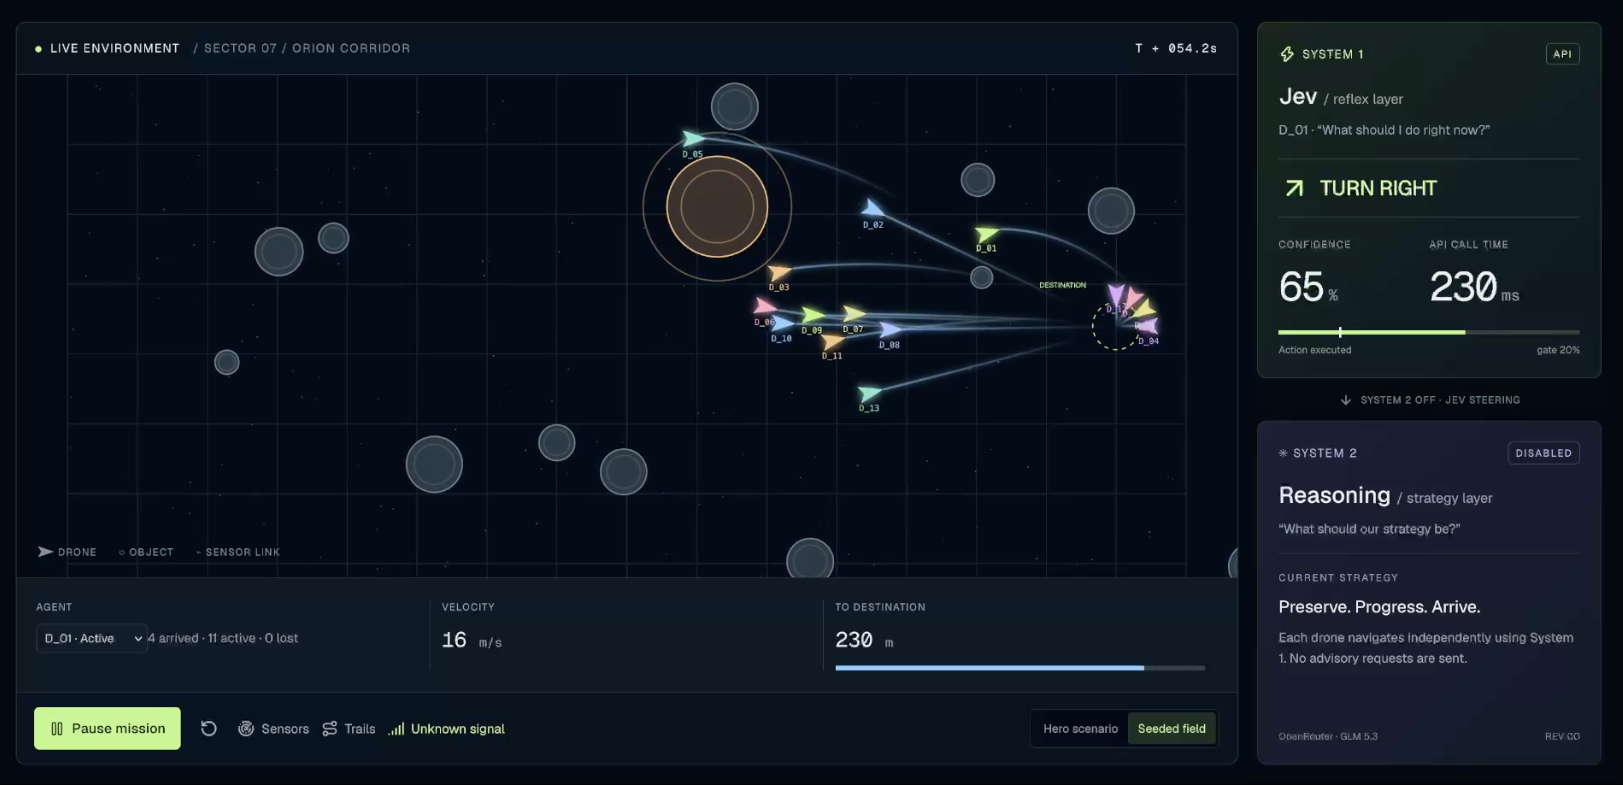
Real-time drone swarm autonomy simulation using Jev for fast System 1 reflex decisions and collision avoidance, with optional System 2 reasoning for strategic guidance

How it uses Jev

An interactive multi-drone autonomy simulation powered by TypeSafe Jev, exploring a simple question: what happens when fast, typed System 1 reflexes can ask a slower System 2 reasoning model for advice without giving up control?

Source: community catalog. Details and metrics reflect the published community snapshot and are not a performance endorsement. Documentation details extracted from GitHub · the README · the project website.
Keep exploring

Similar to jev-reflex-autonomy-lab

Browse all
hundred project preview
Games & simulations
100 AI NPCs live in a tiny town. Jev chooses the next action; the world writes the story.
jev-games project preview
Games & simulations
Visual Jev lab for multiple games and emulator platforms
amigos-jev project preview
Games & simulations
a free multi-modal jev API for everyone
jev-lab project preview
Benchmarks & research
TypeScript experiments, evaluations, and latency benchmarks for TypeSafe's Jev model
reflex (kaustav1996) project preview
A coding agent and personal assistant with System One reflexes (TypeSafe Jev) on top of the Pi coding agent
Jev for robotics
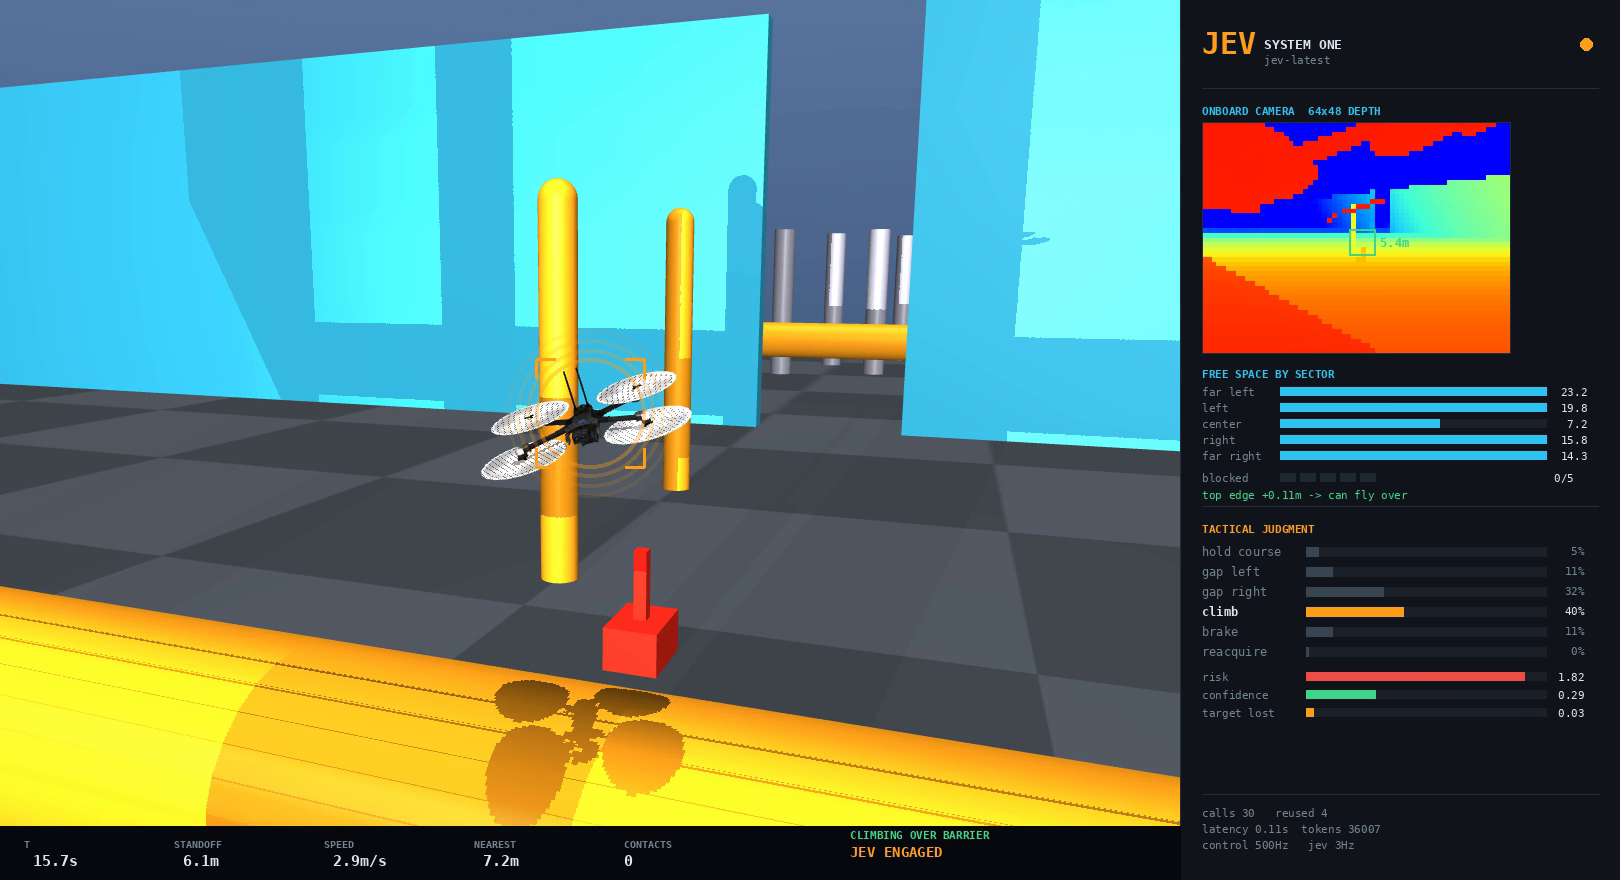
Camera-only autonomous drone in MuJoCo with a small judgment model (TypeSafe Jev) in the loop at 2.5Hz
jev-autopilot project preview
Jev for robotics
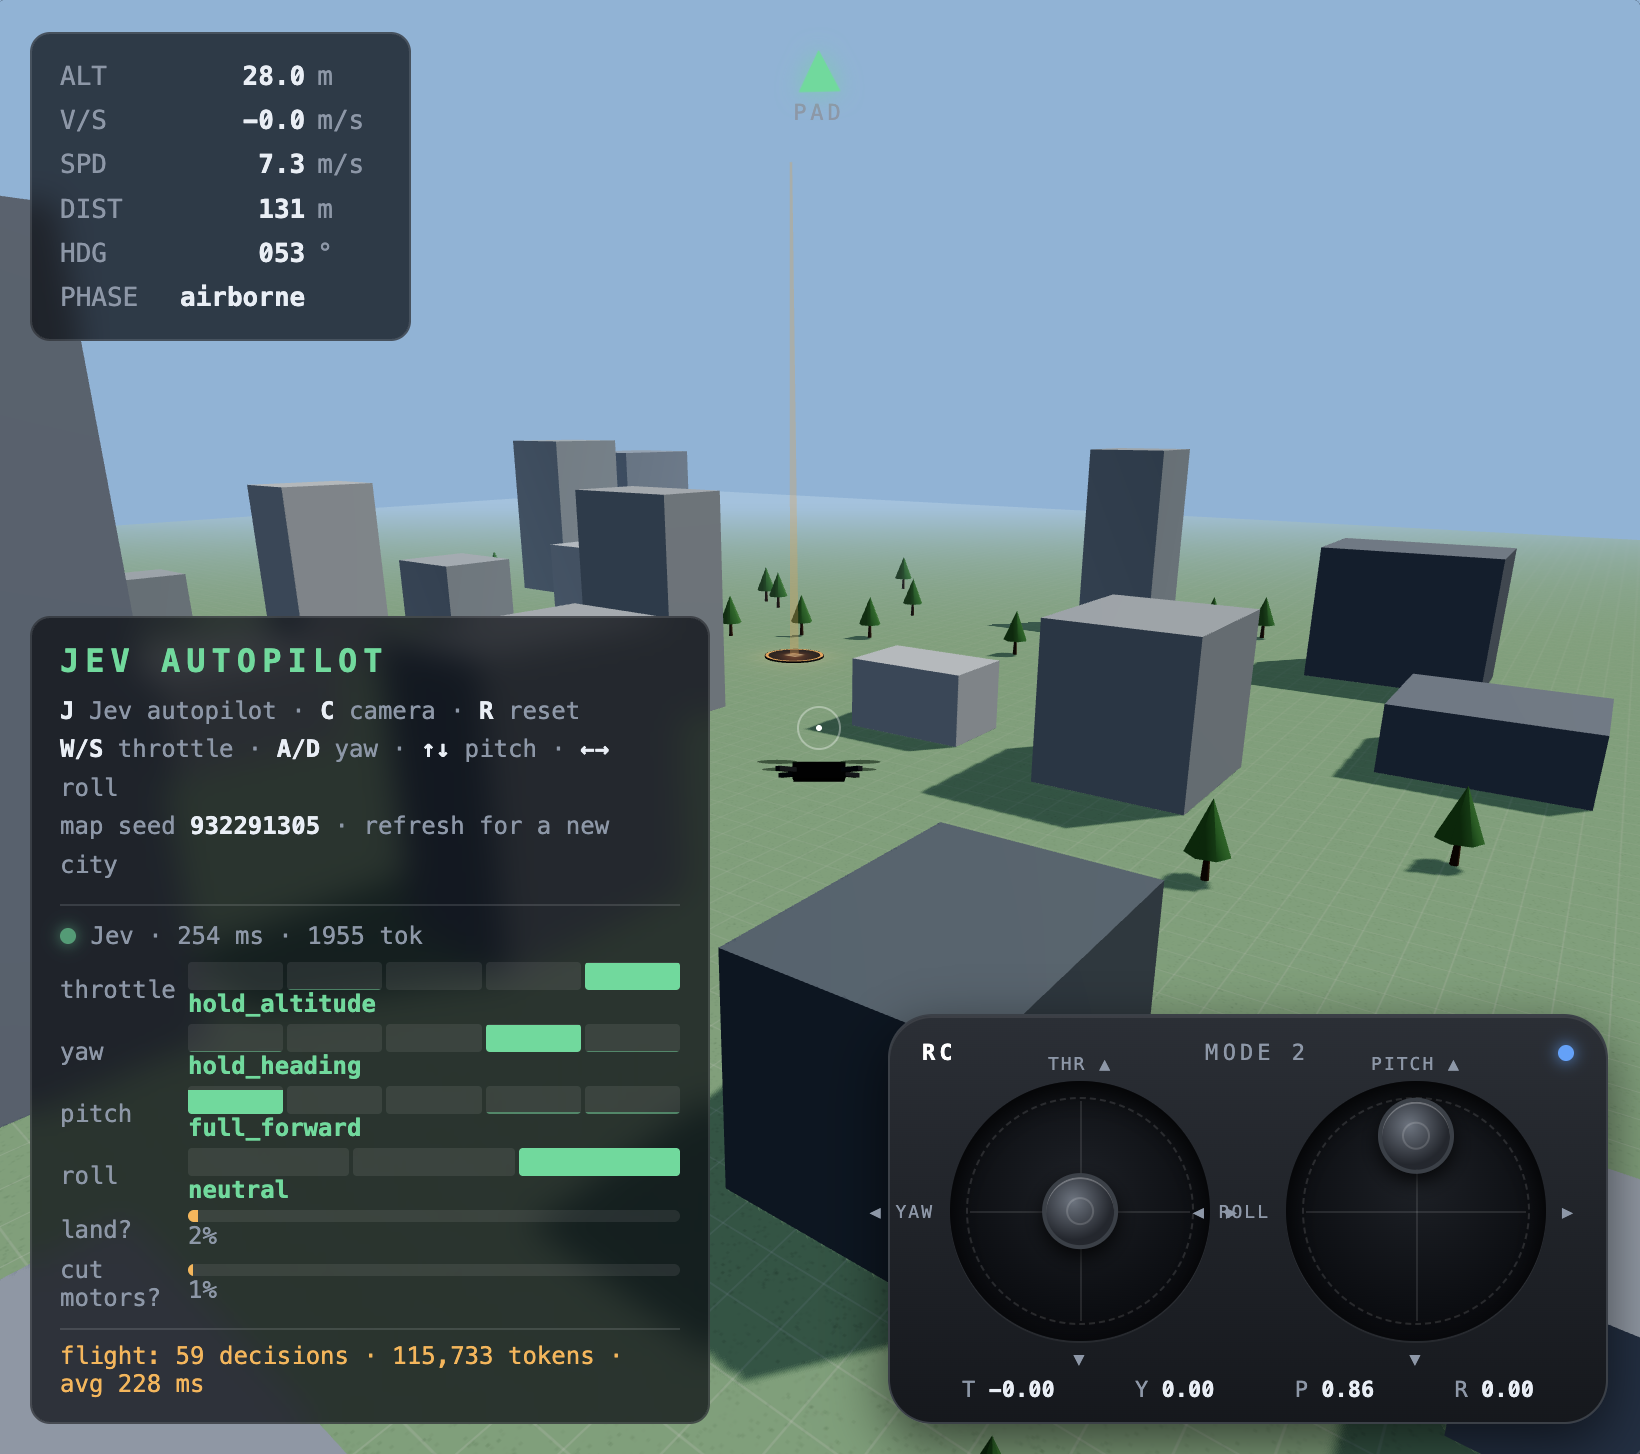
This demo uses Jev from TypeSafe AI to autonomously fly a drone in a random city from point A to point B, avoiding obstacles along the way. A trip costs $0.01.
reflex project preview
Benchmarks & research
A small open decision model: state + typed questions -> calibrated probabilities. A Jev / System One re-creation on Qwen3.5.
jev-2048 project preview
Benchmarks & research
An instrumented 2048 web lab where every move is a Jev (TypeSafe AI System One) Choice, with no heuristic fallback | 用 Jev 决策模型驱动每一步的 2048 网页实验台,概率、置信度、延迟与成本全部摊开可见,且刻意不做启发式兜底